

MI Based Registration of Multi-Sensor and Multi-Temporal Images
183
in the experiments, registration consistency described in the next section is
employed to evaluate the performances of different algorithms.
7.2
Registration Consistency
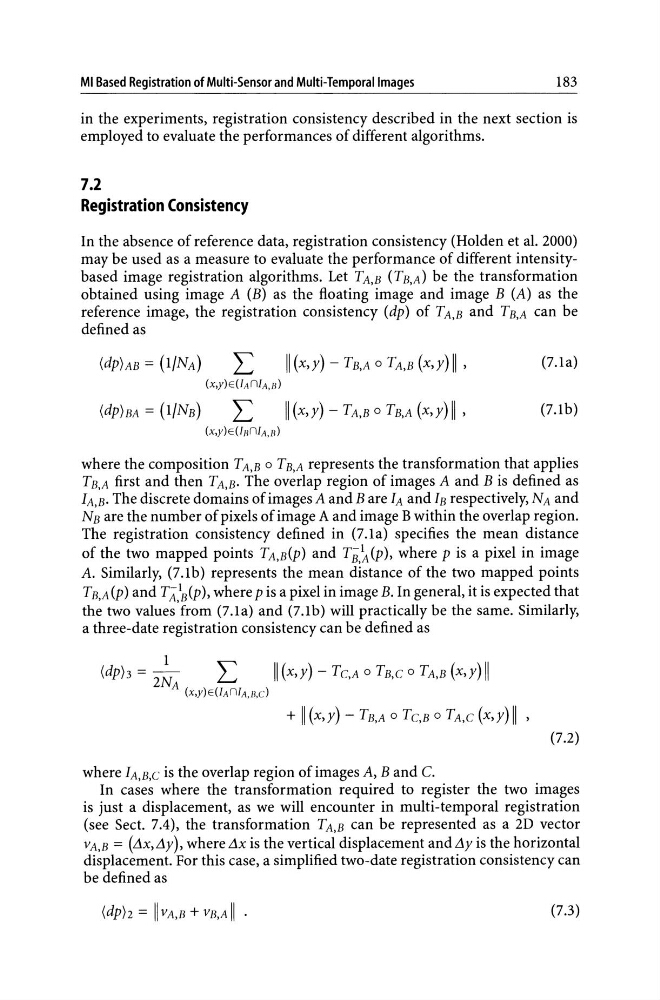
In the absence of reference data, registration consistency (Holden et al. 2000)
may be used as a measure to evaluate the performance of different intensitybased image registration algorithms. Let TA,B (TB,A) be the transformation
obtained using image A (B) as the floating image and image B (A) as the
reference image, the registration consistency (dp) of TA,B and TB,A can be
defined as
I I (x,y) - TB,A 0 TA,B (x,y) II '
(7.la)
(dp)BA = (l/NB)
I I (x,y) - TA,B 0 TB,A (x,y) I I '
(7.lb)
where the composition TA,B 0 TB,A represents the transformation that applies
TB,A first and then TA,B. The overlap region of images A and B is defined as
IA,B. The discrete domains of images A and Bare hand IB respectively, NA and
N B are the number of pixels of image A and image B within the overlap region.
The registration consistency defined in (7.la) specifies the mean distance
of the two mapped points TA,B(P) and Tii,~(p), where p is a pixel in image
A. Similarly, (7.lb) represents the mean distance of the two mapped points
T B,A (p) and TA,~(P)' where p is a pixel in image B. In general, it is expected that
the two values from (7.la) and (7.lh) will practically he the same. Similarly,
a three-date registration consistency can be defined as
1
(dp)3 = -
"
I I (x,y) - TC,A 0 TB,C 0 TA,B (x,y) II
2NA
~
(x,y) E(IA nIA,B,cl
+ I I (x,y) - TB,A 0 TC,B 0 TA,C (x,y) I I '
(7.2)
where IA,B,C is the overlap region of images A, Band C.
In cases where the transformation required to register the two images
is just a displacement, as we will encounter in multi-temporal registration
(see Sect. 7.4), the transformation TA,B can be represented as a 2D vector
VA,B = (.1x,.1y), where.1x is the vertical displacement and.1y is the horizontal
displacement. For this case, a simplified two-date registration consistency can
be defined as
(7.3)