

MI Based Registration of Multi-Sensor and Multi-Temporal Images
195
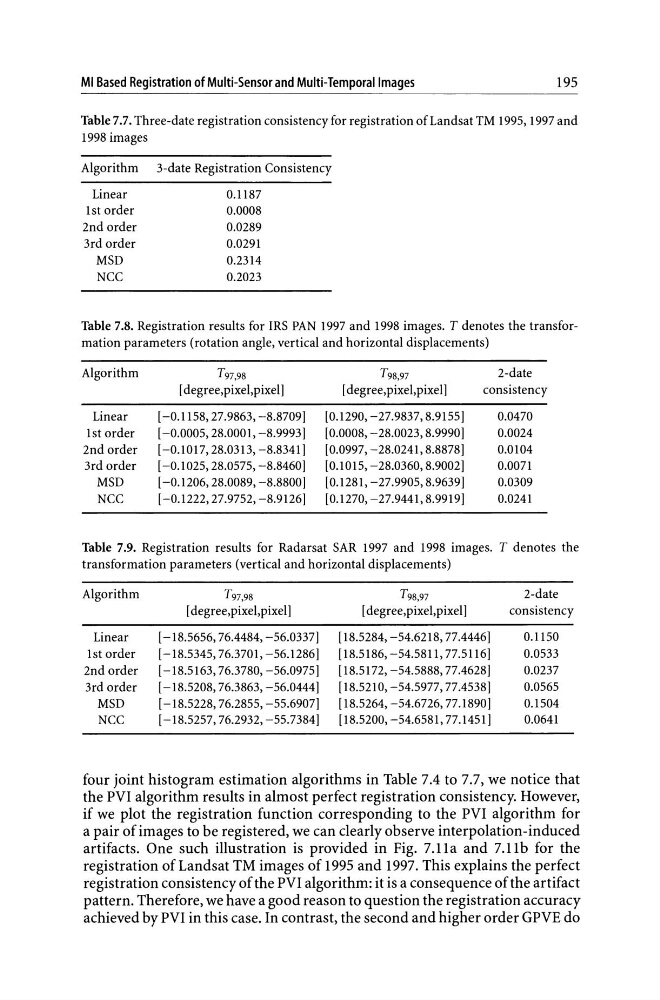
Table 7.7. Three-date registration consistency for registration of Landsat TM 1995, 1997 and
1998 images
Algorithm 3-date Registration Consistency
Linear
0.1187
1st order
0.0008
2nd order
0.0289
3rd order
0.0291
MSD
0.2314
NCC
0.2023
Table 7.8. Registration results for IRS PAN 1997 and 1998 images. T denotes the transformation parameters (rotation angle, vertical and horizontal displacements)
Algorithm
T97,98
T98,97
2-date
[ degree,pixel,pixel]
[ degree,pixel,pixel]
consistency
Linear
[-0.1158,27.9863, -8.8709]
[0.1290, -27.9837, 8.9155]
0.0470
1st order
[-0.0005,28.0001, -8.9993]
[0.0008, -28.0023, 8.9990]
0.0024
2nd order
[-0.1017,28.0313, -8.8341]
[0.0997, -28.0241, 8.8878]
0.0104
3rd order
[-0.1025,28.0575, -8.8460]
[0.1015, -28.0360, 8.9002]
0.0071
MSD
[-0.1206,28.0089, -8.8800]
[0.1281, -27.9905, 8.9639]
0.0309
NCC
[-0.1222,27.9752, -8.9126]
[0.1270, -27.9441, 8.9919]
0.0241
Table 7.9. Registration results for Radarsat SAR 1997 and 1998 images. T denotes the
transformation parameters (vertical and horizontal displacements)
Algorithm
T97,98
T98,97
2-date
[ degree,pixel,pixel]
[ degree,pixel,pixel]
consistency
Linear
[-18.5656,76.4484, -56.0337]
[18.5284, -54.6218, 77.4446]
0.1150
1st order
[-18.5345,76.3701, -56.1286]
[18.5186, -54.5811, 77.5116]
0.0533
2nd order
[-18.5163,76.3780, -56.0975]
[18.5172, -54.5888, 77.4628]
0.0237
3rd order
[-18.5208,76.3863, -56.0444]
[18.5210, -54.5977, 77.4538]
0.0565
MSD
[-18.5228,76.2855, -55.6907]
[18.5264, -54.6726, 77.1890]
0.1504
NCC
[-18.5257,76.2932, -55.7384]
[18.5200, -54.6581, 77.1451]
0.0641
four joint histogram estimation algorithms in Table 7.4 to 7.7, we notice that
the PVI algorithm results in almost perfect registration consistency. However,
if we plot the registration function corresponding to the PVI algorithm for
a pair of images to be registered, we can dearly observe interpolation-induced
artifacts. One such illustration is provided in Fig. 7.lla and 7.llb for the
registration of Landsat TM images of 1995 and 1997. This explains the perfect
registration consistency of the PVI algorithm: it is a consequence of the artifact
pattern. Therefore, we have a good reason to question the registration accuracy
achieved by PVI in this case. In contrast, the second and higher order GPVE do