

MI Based Registration of Multi-Sensor and Multi-Temporal Images
193
a
b
c
d
e
f
g
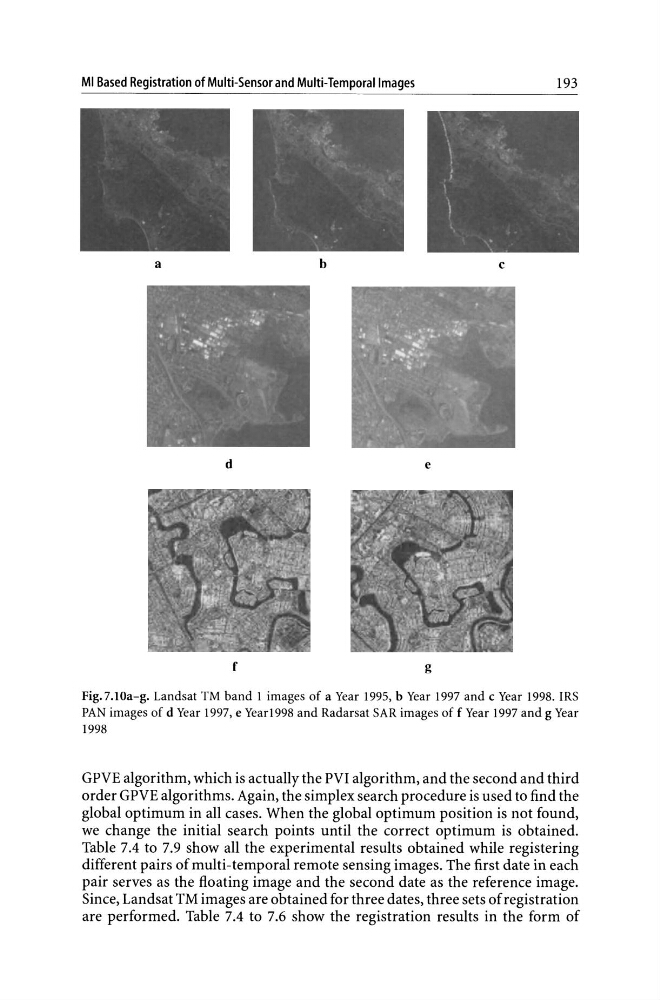
Fig.7.lOa-g. Landsat TM band I images of a Year 1995, b Year 1997 and c Year 1998. IRS
PAN images of d Year 1997, e Year1998 and Radarsat SAR images of f Year 1997 and g Year
1998
GPVE algorithm, which is actually the PVI algorithm, and the second and third
order GPVE algorithms. Again, the simplex search procedure is used to find the
global optimum in all cases. When the global optimum position is not found,
we change the initial search points until the correct optimum is obtained.
Table 7.4 to 7.9 show all the experimental results obtained while registering
different pairs of multi-temporal remote sensing images. The first date in each
pair serves as the floating image and the second date as the reference image.
Since, Landsat TM images are obtained for three dates, three sets of registration
are performed. Table 7.4 to 7.6 show the registration results in the form of