

100
3: Hua-mei Chen
y. =(Yi'Y)
Y. = (Yi + I, Y j + I)
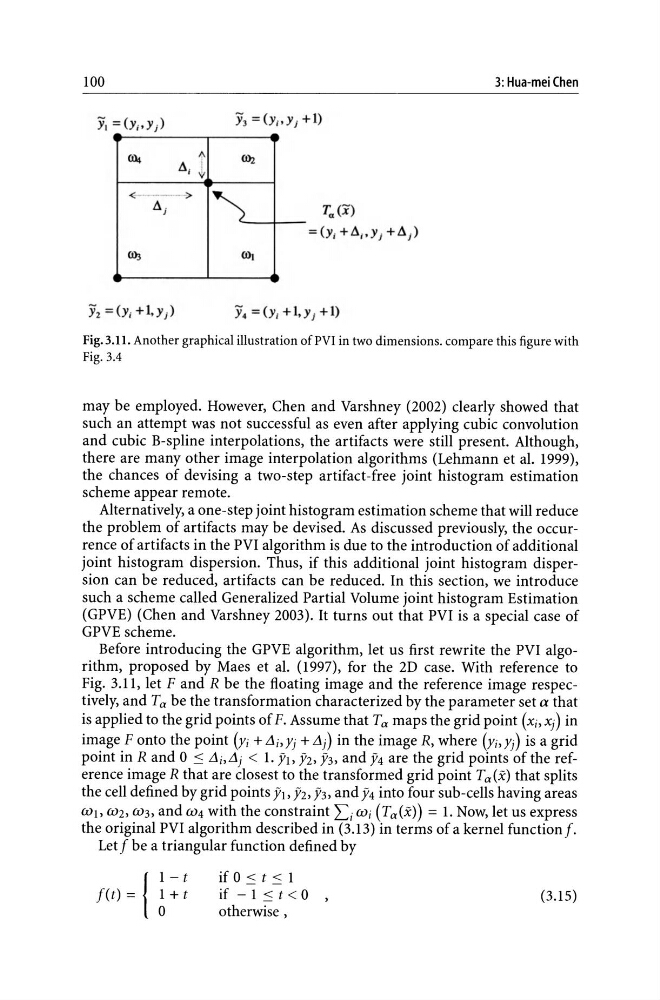
Fig.3.ll. Another graphical illustration ofPVI in two dimensions. compare this figure with
Fig. 3.4
may be employed. However, Chen and Varshney (2002) clearly showed that
such an attempt was not successful as even after applying cubic convolution
and cubic B-spline interpolations, the artifacts were still present. Although,
there are many other image interpolation algorithms (Lehmann et al. 1999),
the chances of devising a two-step artifact-free joint histogram estimation
scheme appear remote.
Alternatively, a one-step joint histogram estimation scheme that will reduce
the problem of artifacts may be devised. As discussed previously, the occurrence of artifacts in the PVI algorithm is due to the introduction of additional
joint histogram dispersion. Thus, if this additional joint histogram dispersion can be reduced, artifacts can be reduced. In this section, we introduce
such a scheme called Generalized Partial Volume joint histogram Estimation
(GPVE) (Chen and Varshney 2003). It turns out that PVI is a special case of
GPVE scheme.
Before introducing the GPVE algorithm, let us first rewrite the PVI algorithm, proposed by Maes et al. (1997), for the 2D case. With reference to
Fig. 3.11, let F and R be the floating image and the reference image respectively, and T a be the transformation characterized by the parameter set a that
is applied to the grid points of F. Assume that Ta maps the grid point (Xi,Xj) in
image F onto the point (yi + Lli,Yj + Llj) in the image R, where (Yi,Yj) is a grid
point in Rand 0 :::: Lli,Llj < l. YI> 5'2, Y3, and Y4 are the grid points of the reference image R that are closest to the transformed grid point Ta(x) that splits
the cell defined by grid points YI, Y2, Y3, and y 4 into four sub-cells having areas
WI> W2, W3, and W4 with the constraint Li Wi (Ta(x») = l. Now, let us express
the original PVI algorithm described in (3.13) in terms of a kernel function f.
Let f be a triangular function defined by
1
1 - t
f(t) =
~ + t
if 0 :::: t :::: 1
if - 1 :::: t < 0
otherwise,
(3.15)