

13 Tracking of Moving Objects with Accuracy Guarantees
301
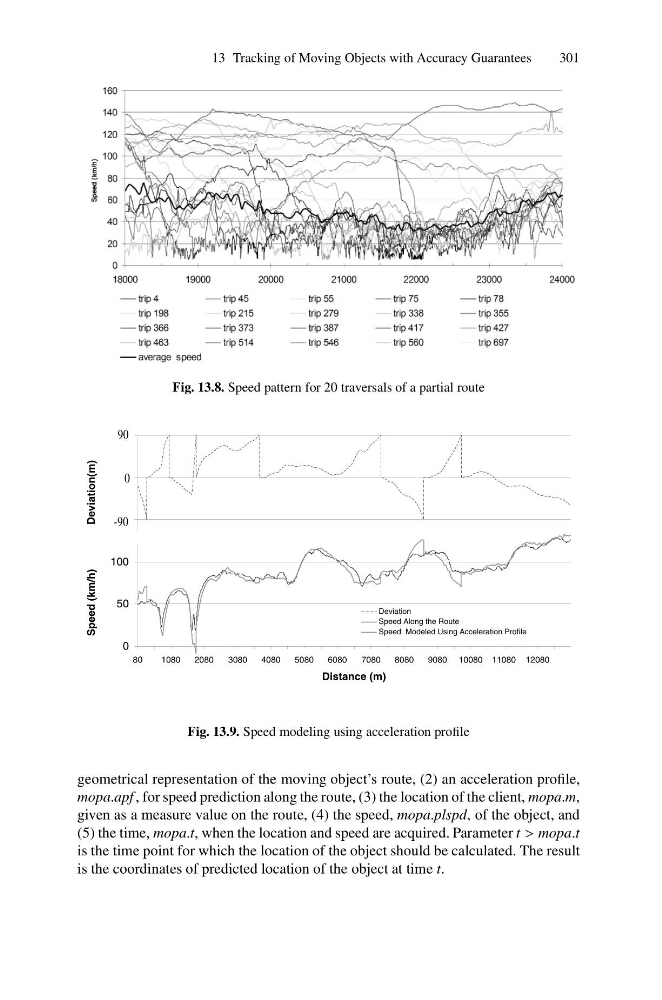
Fig. 13.8. Speed pattern for 20 traversals of a partial route
0
50
100
150
200
250
80
1080
2080
3080
4080
5080
6080
7080
8080
9080 10080 11080 12080
Distance (m)
Speed (km/h) Deviation(m)
Deviation
Speed Along the Route
Speed Modeled Using Acceleration Profile
90
0
-90
Fig. 13.9. Speed modeling using acceleration profile
geometrical representation of the moving object’s route, (2) an acceleration profile,
mopa.apf , for speed prediction along the route, (3) the location of the client, mopa.m,
given as a measure value on the route, (4) the speed, mopa.plspd, of the object, and
(5) the time, mopa.t, when the location and speed are acquired. Parameter t > mopa.t
is the time point for which the location of the object should be calculated. The result
is the coordinates of predicted location of the object at time t.