

300
Alminas ˇ
Civilis, Christian S. Jensen, and Stardas Pakalnis
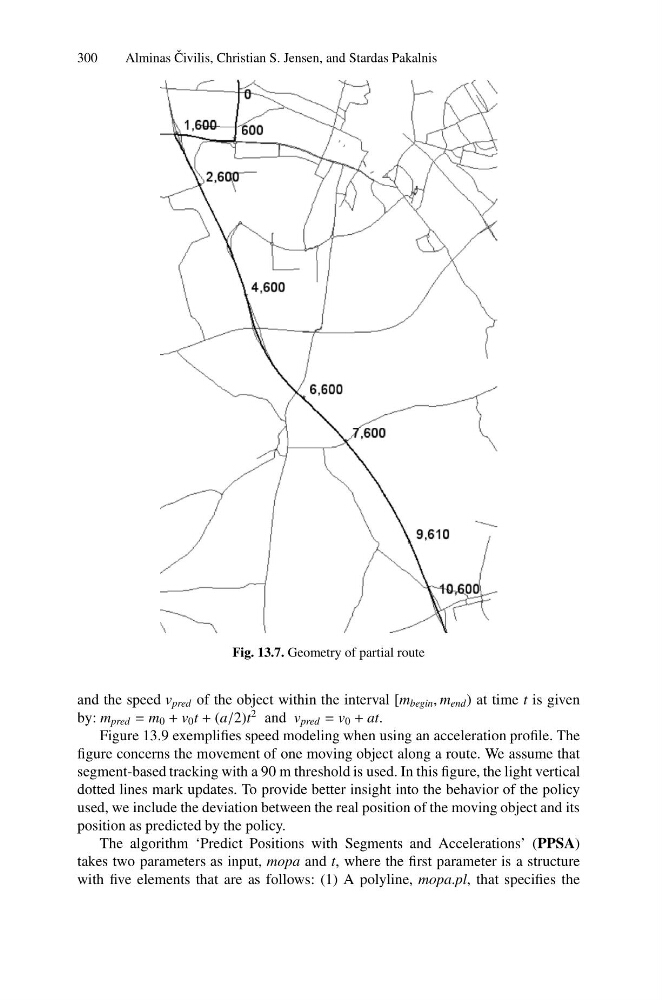
Fig. 13.7. Geometry of partial route
and the speed v pred of the object within the interval [m begin , m end ) at time t is given
by: m pred = m 0 + v 0 t + (a/2)t
2 and v pred = v 0 + at.
Figure 13.9 exemplifies speed modeling when using an acceleration profile. The
figure concerns the movement of one moving object along a route. We assume that
segment-based tracking with a 90 m threshold is used. In this figure, the light vertical
dotted lines mark updates. To provide better insight into the behavior of the policy
used, we include the deviation between the real position of the moving object and its
position as predicted by the policy.
The algorithm ‘Predict Positions with Segments and Accelerations’ (PPSA)
takes two parameters as input, mopa and t, where the first parameter is a structure
with five elements that are as follows: (1) A polyline, mopa.pl, that specifies the