

254
A. Collin et al.
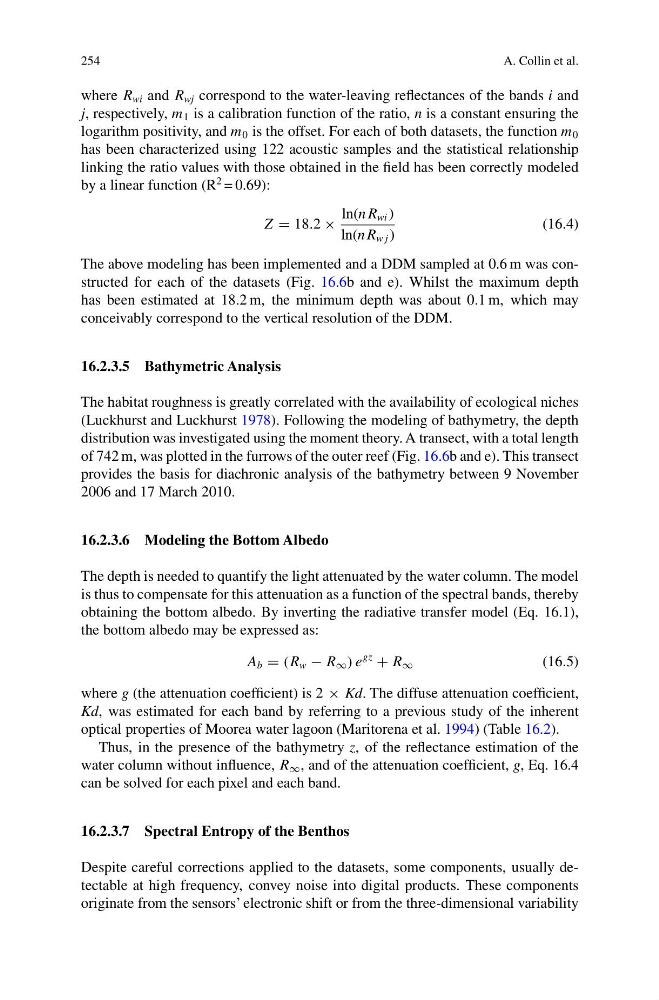
where R wi and R wj correspond to the water-leaving reflectances of the bands i and
j, respectively, m 1 is a calibration function of the ratio, n is a constant ensuring the
logarithm positivity, and m 0 is the offset. For each of both datasets, the function m 0
has been characterized using 122 acoustic samples and the statistical relationship
linking the ratio values with those obtained in the field has been correctly modeled
by a linear function (R
2 = 0.69):
Z = 18.2 ×
ln(nR wi )
ln(nR wj )
(16.4)
The above modeling has been implemented and a DDM sampled at 0.6 m was constructed for each of the datasets (Fig. 16.6b and e). Whilst the maximum depth
has been estimated at 18.2 m, the minimum depth was about 0.1 m, which may
conceivably correspond to the vertical resolution of the DDM.
16.2.3.5 Bathymetric Analysis
The habitat roughness is greatly correlated with the availability of ecological niches
(Luckhurst and Luckhurst 1978). Following the modeling of bathymetry, the depth
distribution was investigated using the moment theory. A transect, with a total length
of 742 m, was plotted in the furrows of the outer reef (Fig. 16.6b and e). This transect
provides the basis for diachronic analysis of the bathymetry between 9 November
2006 and 17 March 2010.
16.2.3.6 Modeling the Bottom Albedo
The depth is needed to quantify the light attenuated by the water column. The model
is thus to compensate for this attenuation as a function of the spectral bands, thereby
obtaining the bottom albedo. By inverting the radiative transfer model (Eq. 16.1),
the bottom albedo may be expressed as:
A b = (R w − R ∞ ) e
gz
+ R ∞
(16.5)
where g (the attenuation coefficient) is 2 × Kd. The diffuse attenuation coefficient,
Kd, was estimated for each band by referring to a previous study of the inherent
optical properties of Moorea water lagoon (Maritorena et al. 1994) (Table 16.2).
Thus, in the presence of the bathymetry z, of the reflectance estimation of the
water column without influence, R ∞ , and of the attenuation coefficient, g, Eq. 16.4
can be solved for each pixel and each band.
16.2.3.7 Spectral Entropy of the Benthos
Despite careful corrections applied to the datasets, some components, usually detectable at high frequency, convey noise into digital products. These components
originate from the sensors’ electronic shift or from the three-dimensional variability