

ICHIRO FUKUMORI
332
displacement, respectively. The approximated control a W is the magnitude of
wind error defined on the same coarse horizontal grid. These approximated
errors are related to those of the model state and model forcing by,
,
,
,
vel
u
vel
v
K
K
W
G
G
G
G
u D Oa
v D Oa
Ș D Oa
IJ Oa
(27)
where Gu, Gv, GK K, and GW W are errors of model zonal and meridional velocity,
ve
Ds consist of
rtical displacement, and wind stress, respectively. The
structures of vertical dynamic modes of respective variables that project the
errors vertically to the model grid. O denotes the horizontal mapping
operator from the coarse grid to the model grid. Errors of other state
variables are diagnostically derived using estimates in Eq (27). For instance,
errors of temperature T and salinity S are derived from those of
displacement by,
,
z
z
G
G
G
G
w
w
w
w
nd errors of sea level can be defined as a
perature and salinity). Errors from different
cell consisting of nearly
120
T
S
T
Ș S
Ș
(28)
a
function of GK K and density
(tem
partitions are summed
together to form the overall model error estimate.
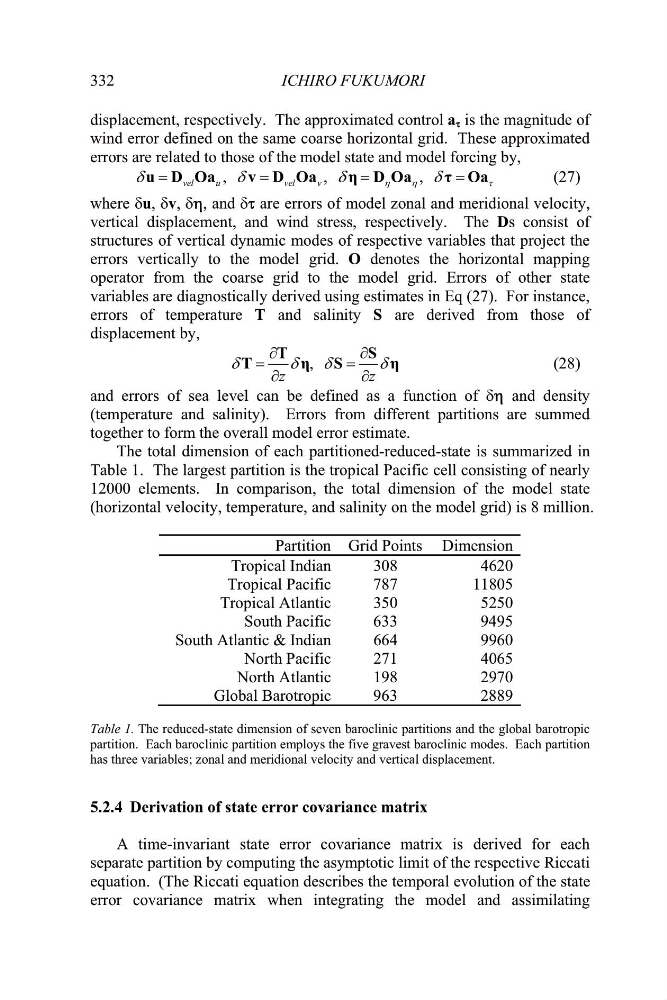
The total dimension of each partitioned-reduced-state is summarized in
Table 1. The largest partition is the tropical Pacific
00 elements. In comparison, the total dimension of the model state
(horizontal velocity, temperature, and salinity on the model grid) is 8 million.
Partition Grid Points Dimension
Tropical Indian
308
4620
Tropic
T
South
Glob
al Pacific
787
11805
ropical Atlantic
350
5250
South Pacific
633
9495
Atlantic & Indian
664
9960
North Pacific
271
4065
North Atlantic
198
2970
al Barotropic
963
2889
Table 1. The reduced-state dimension of seven baroc
artitions and
bal barotropic
artition. Each barocl
e five
t baroclinic m
ach partition
x is derived for each
eparate partition by computing the asymptotic limit of the respective Riccati
equ
linic p
graves
the glo
odes. E
p
inic partition employs th
has three variables; zonal and meridional velocity and vertical displacement.
.2.4 Derivation of state error covariance matrix
5
A time-invariant state error covariance matri
s
ation. (The Riccati equation describes the temporal evolution of the state
error covariance matrix when integrating the model and assimilating