

277
numerator for all possible states) which can be ignored in determining
the maximum of the posterior pdf. The gaussian distributions (6) and
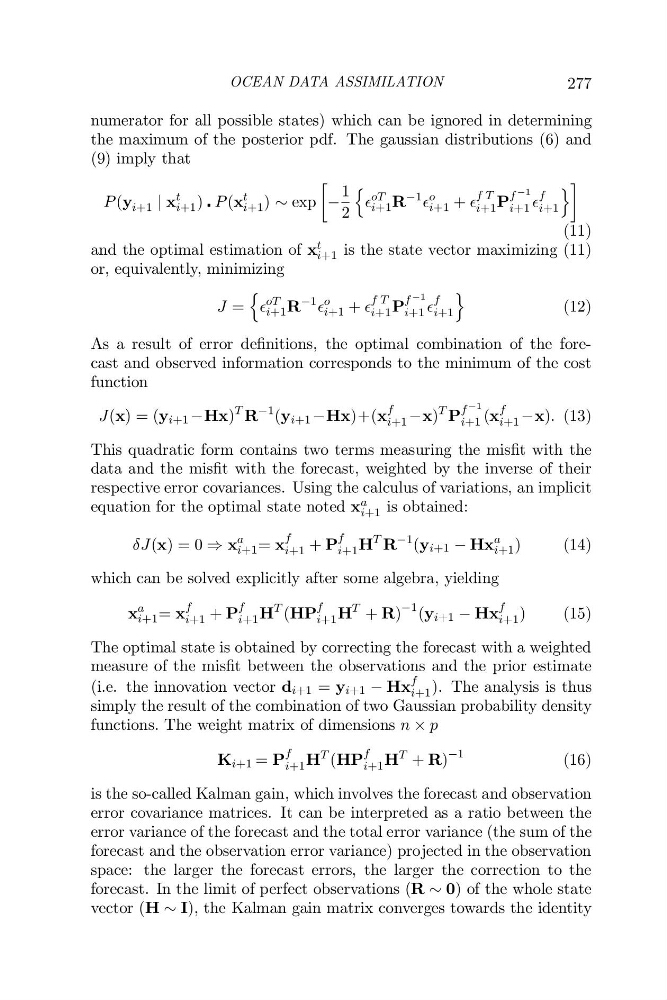
(9) imply that
P (y i+1 | x
t
i+1 ) P (x
t
i+1 ) exp
1
2
q
oT
i+1 R
31
o
i+1 +
f T
i+1 P
f 31
i+1
f
i+1
r
(11)
and the optimal estimation of x
t
i+1 is the state vector maximizing (11)
or, equivalently, minimizing
J =
q
oT
i+1 R
31
o
i+1 +
f T
i+1 P
f 31
i+1
f
i+1
r
(12)
As a result of error definitions, the optimal combination of the forecast and observed information corresponds to the minimum of the cost
function
J(x) = (y i+1 Hx)
T R
31
(y i+1 Hx)+(x
f
i+1 x)
T P
f 31
i+1 (x
f
i+1 x). (13)
This quadratic form contains two terms measuring the misfit with the
data and the misfit with the forecast, weighted by the inverse of their
respective error covariances. Using the calculus of variations, an implicit
equation for the optimal state noted x a
i+1 is obtained:
J(x) = 0 , x
a
i+1 = x
f
i+1 + P
f
i+1 H
T R
31
(y i+1 Hx
a
i+1 )
(14)
which can be solved explicitly after some algebra, yielding
x
a
i+1 = x
f
i+1 + P
f
i+1 H
T
(HP
f
i+1 H
T
+ R)
31
(y i+1 Hx
f
i+1 )
(15)
The optimal state is obtained by correcting the forecast with a weighted
measure of the misfit between the observations and the prior estimate
(i.e. the innovation vector d i+1 = y i+1 Hx
f
i+1 ). The analysis is thus
simply the result of the combination of two Gaussian probability density
functions. The weight matrix of dimensions n × p
K i+1 = P
f
i+1 H
T
(HP
f
i+1 H
T
+ R)
31
(16)
is the so-called Kalman gain, which involves the forecast and observation
error covariance matrices. It can be interpreted as a ratio between the
error variance of the forecast and the total error variance (the sum of the
forecast and the observation error variance) projected in the observation
space: the larger the forecast errors, the larger the correction to the
forecast. In the limit of perfect observations (R 0) of the whole state
vector (H I), the Kalman gain matrix converges towards the identity
OCEAN DATA ASSIMILATION