

276
PIERRE BRASSEUR
imperfections which increase the forecast error covariance. Understanding the actual benefits and the practical limitations of error covariance
propagation through model dynamics has been a major research issue
over recent years. Although simple in its algebraic form, this equation
contains several major di!culties that prevent an explicit computation
in the context of realistic models, as discussed in the following sections.
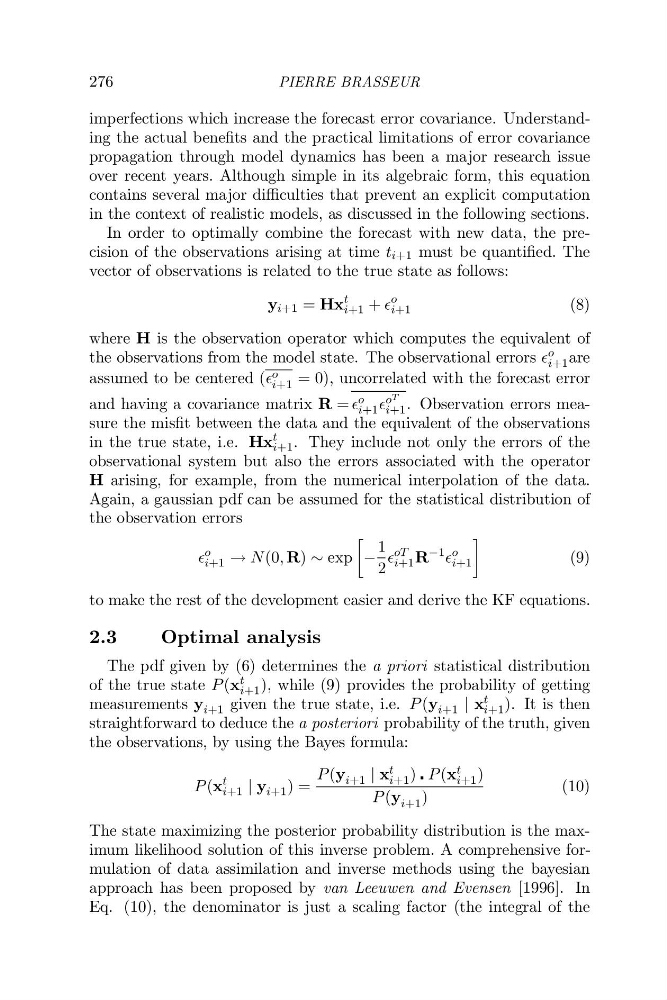
In order to optimally combine the forecast with new data, the precision of the observations arising at time t i+1 must be quantified. The
vector of observations is related to the true state as follows:
y i+1 = Hx
t
i+1 +
o
i+1
(8)
where H is the observation operator which computes the equivalent of
the observations from the model state. The observational errors
o
i+1 are
assumed to be centered ( o
i+1 = 0), uncorrelated with the forecast error
and having a covariance matrix R = o
i+1 o T
i+1 . Observation errors measure the misfit between the data and the equivalent of the observations
in the true state, i.e. Hx
t
i+1 . They include not only the errors of the
observational system but also the errors associated with the operator
H arising, for example, from the numerical interpolation of the data.
Again, a gaussian pdf can be assumed for the statistical distribution of
the observation errors
o
i+1 $ N(0, R) exp
1
2
oT
i+1 R
31
o
i+1
(9)
to make the rest of the development easier and derive the KF equations.
2.3
Optimal analysis
The pdf given by (6) determines the a priori statistical distribution
of the true state P (x
t
i+1 ), while (9) provides the probability of getting
measurements y i+1 given the true state, i.e. P (y i+1 | x
t
i+1 ). It is then
straightforward to deduce the a posteriori probability of the truth, given
the observations, by using the Bayes formula:
P (x
t
i+1 | y i+1 ) =
P (y i+1 | x t
i+1 ) P (x t
i+1 )
P (y i+1 )
(10)
The state maximizing the posterior probability distribution is the maximum likelihood solution of this inverse problem. A comprehensive formulation of data assimilation and inverse methods using the bayesian
approach has been proposed by van Leeuwen and Evensen [1996]. In
Eq. (10), the denominator is just a scaling factor (the integral of the