

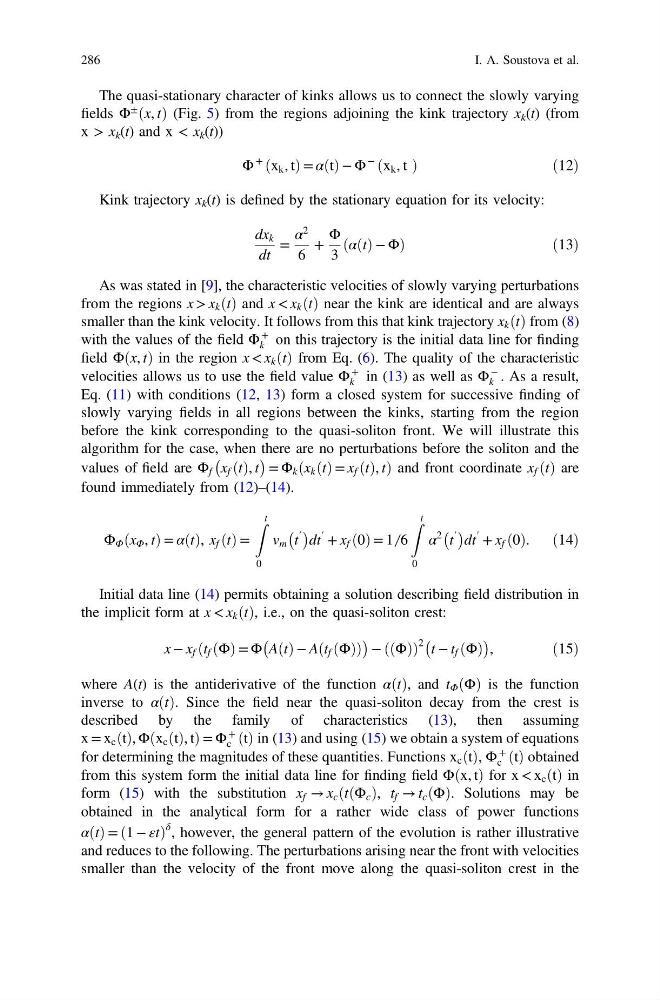
The quasi-stationary character of kinks allows us to connect the slowly varying
fields Φ
±
ðx, tÞ (Fig. 5) from the regions adjoining the kink trajectory x k (t) (from
x > x k (t) and x < x k (t))
Φ
+
ðx k , tÞ = αðtÞ − Φ
−
ðx k , t Þ
ð 12Þ
Kink trajectory x k (t) is defined by the stationary equation for its velocity:
dx k
dt
=
α
2
6
+
Φ
3
αðtÞ − Φ
ð
Þ
ð 13Þ
As was stated in [9], the characteristic velocities of slowly varying perturbations
from the regions x > x k t
ð Þ and x < x k t
ð Þ near the kink are identical and are always
smaller than the kink velocity. It follows from this that kink trajectory x k t
ð Þ from (8)
with the values of the field Φ
+
k on this trajectory is the initial data line for finding
field Φðx, tÞ in the region x < x k t
ð Þ from Eq. (6). The quality of the characteristic
velocities allows us to use the field value Φ
+
k in (13) as well as Φ
−
k . As a result,
Eq. (11) with conditions (12, 13) form a closed system for successive finding of
slowly varying fields in all regions between the kinks, starting from the region
before the kink corresponding to the quasi-soliton front. We will illustrate this
algorithm for the case, when there are no perturbations before the soliton and the
values of field are Φ f x f ðtÞ, t
À
Á
= Φ k ðx k ðtÞ = x f ðtÞ, tÞ and front coordinate x f t
ð Þ are
found immediately from (12)–(14).
Φ Φ x Φ , t
ð
Þ= αðtÞ, x f t
ð Þ =
Z t
0
v m t
′
À Á
dt
′ + x f 0
ð Þ = 1 ̸ 6
Z t
0
α
2 t
′
À Á
dt
′ + x f 0
ð Þ.
ð14Þ
Initial data line (14) permits obtaining a solution describing field distribution in
the implicit form at x < x k t
ð Þ, i.e., on the quasi-soliton crest:
x − x f ðt f ðΦÞ = Φ AðtÞ − Aðt f ðΦÞÞ
À
Á − ððΦÞÞ
2 t − t f ðΦÞ
À
Á
,
ð15Þ
where A(t) is the antiderivative of the function αðtÞ, and t Φ ðΦÞ is the function
inverse to αðtÞ. Since the field near the quasi-soliton decay from the crest is
described by the family of characteristics (13), then assuming
x = x c ðtÞ, Φðx c ðtÞ, tÞ = Φ
+
c ðtÞ in (13) and using (15) we obtain a system of equations
for determining the magnitudes of these quantities. Functions x c ðtÞ, Φ
+
c ðtÞ obtained
from this system form the initial data line for finding field Φðx, tÞ for x < x c ðtÞ in
form (15) with the substitution x f → x c ðtðΦ c Þ, t f → t c ðΦÞ. Solutions may be
obtained in the analytical form for a rather wide class of power functions
αðtÞ = ð1 − εtÞ
δ , however, the general pattern of the evolution is rather illustrative
and reduces to the following. The perturbations arising near the front with velocities
smaller than the velocity of the front move along the quasi-soliton crest in the
286
I. A. Soustova et al.