

Autonomous Sea Surface Vehicles 13.3 Naval Architecture of AUSV Design 329
Part B | 13.3
Viscous wake
Boundary
layer
Separated
flow
λ
Fig. 13.7 Idealization of the of flow regions types around
a ship advancing in calm water
wave patterns. Higher-order versions of these methods that use curved panels defined by B-spline surfaces [13.28] have been developed, and they have
shown superior convergence and stability characteristics. Panel methods have been extensively tested and
validated both in the case of slow and fast displacement
hull forms [13.29] and for semi-displacement mono and
multi-hulls, where the effect of dynamic trim and sinkage is essential [13.30–32].
Spectral analysis of wave pattern formation applied
to experimental measurements [13.33] and to numerical simulations [13.30–32] has yielded insight into
the wave generation characteristics of displacement
hull forms, such as the relative importance of divergent and transverse wave trains at different speeds. In
terms of energy, the relative importance of the divergent waves, negligible at low speeds with most of the
energy concentrated in the transverse waves, progressively increases with the Froude number to become
dominant for high-speed semi-displacement hull forms
(Fr > 0:55). This ratio is directly dependent on the
shape of the hull.
The solution of the viscous free surface flow around
the hull is today possible with numerical methods that
are able to solve the Reynolds averaged Navier–Stokes
equations (RANS). The sharp free surface separating
air with water was initially solved with surface tracking algorithms and level set methods [13.35] that are
based on the assumption of a smooth and continuous
surface on which dynamic and kinematic wave boundary conditions are satisfied, while more recent surface
capturing algorithms, based on the volume of fluid
technique [13.36] result in a simpler and faster numerical implementation and can inherently deal with wave
breaking or spray flows. In recent validation studies,
these methods have given good results both in cases
of displacement hull forms [13.37] and for planing
hulls [13.38–41]. Fully viscous free surface flow solvers
avoid empirical estimation of the friction and form drag
Position z (m)
y
–0.03
0.01
0.05
0.09
–0.07
–0.11
a)
b)
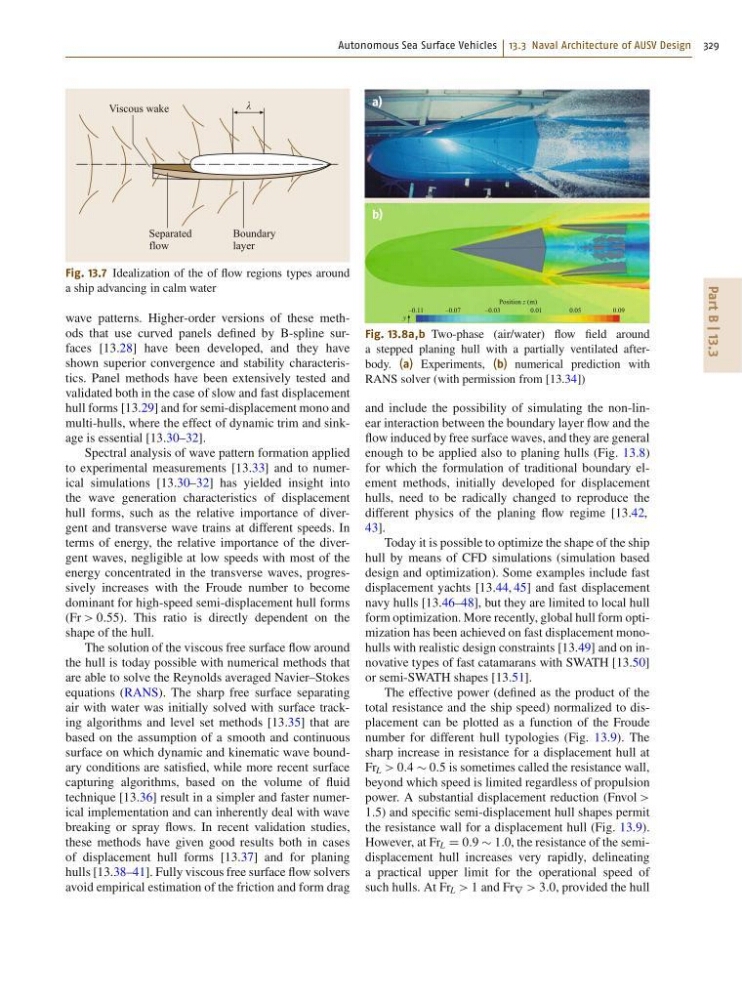
Fig. 13.8a,b Two-phase (air/water) flow field around
a stepped planing hull with a partially ventilated afterbody. (a) Experiments, (b) numerical prediction with
RANS solver (with permission from [13.34])
and include the possibility of simulating the non-linear interaction between the boundary layer flow and the
flow induced by free surface waves, and they are general
enough to be applied also to planing hulls (Fig. 13.8)
for which the formulation of traditional boundary element methods, initially developed for displacement
hulls, need to be radically changed to reproduce the
different physics of the planing flow regime [13.42,
43].
Today it is possible to optimize the shape of the ship
hull by means of CFD simulations (simulation based
design and optimization). Some examples include fast
displacement yachts [13.44, 45] and fast displacement
navy hulls [13.46–48], but they are limited to local hull
form optimization. More recently, global hull form optimization has been achieved on fast displacement monohulls with realistic design constraints [13.49] and on innovative types of fast catamarans with SWATH [13.50]
or semi-SWATH shapes [13.51].
The effective power (defined as the product of the
total resistance and the ship speed) normalized to displacement can be plotted as a function of the Froude
number for different hull typologies (Fig. 13.9). The
sharp increase in resistance for a displacement hull at
Fr L > 0:4 0:5 is sometimes called the resistance wall,
beyond which speed is limited regardless of propulsion
power. A substantial displacement reduction (Fnvol >
1:5) and specific semi-displacement hull shapes permit
the resistance wall for a displacement hull (Fig. 13.9).
However, at Fr L D 0:9 1:0, the resistance of the semidisplacement hull increases very rapidly, delineating
a practical upper limit for the operational speed of
such hulls. At Fr L > 1 and Fr r > 3:0, provided the hull