

Part B | 11.3
292 Part B Autonomous Ocean Vehicles, Subsystems and Control
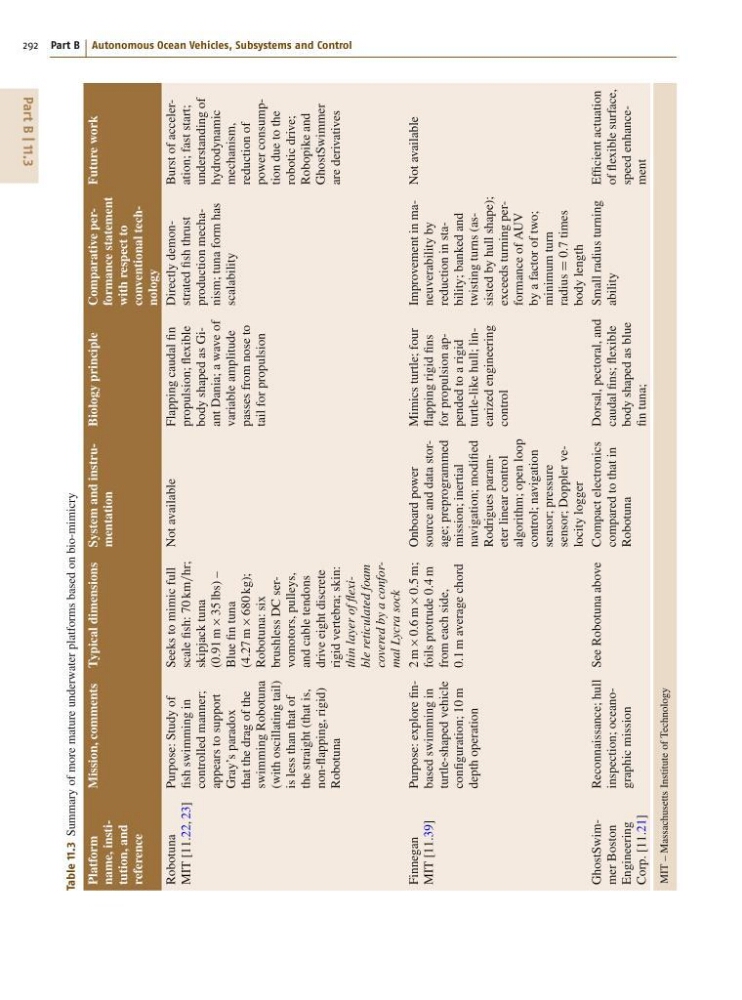
Table 11.3
Summary of more mature underwater platforms based on bio-mimicry
Platform
name, institution, and
reference
Mission, comments Typical dimensions System and instrumentation
Biology principle
Comparative performance statement
with respect to
conventional technology
Future work
Robotuna
MIT [11.22, 23]
Purpose: Study of
fish swimming in
controlled manner;
appears to support
Gray’s paradox
that the drag of the
swimming Robotuna
(with oscillating tail)
is less than that of
the straight (that is,
non-flapping, rigid)
Robotuna
Seeks to mimic full
scale fish: 70 km=hr;
skipjack tuna
(0:91 m
35 lbs) –
Blue fin tuna
(4:27 m
680 kg);
Robotuna: six
brushless DC servomotors, pulleys,
and cable tendons
drive eight discrete
rigid vertebra; skin:
thin layer of flexible reticulated foam
covered by a conformal Lycra sock
Not available
Flapping caudal fin
propulsion; flexible
body shaped as Giant Dania; a wave of
variable amplitude
passes from nose to
tail for propulsion
Directly demonstrated fish thrust
production mechanism; tuna form has
scalability
Burst of acceleration; fast start;
understanding of
hydrodynamic
mechanism,
reduction of
power consumption due to the
robotic drive;
Robopike and
GhostSwimmer
are derivatives
Finnegan
MIT [11.39]
Purpose: explore finbased swimming in
turtle-shaped vehicle
configuration; 10 m
depth operation
2 m
0:6 m
0:5 m;
foils protrude 0:4 m
from each side,
0:1 m average chord
Onboard power
source and data storage; preprogrammed
mission; inertial
navigation; modified
Rodrigues parameter linear control
algorithm; open loop
control; navigation
sensor; pressure
sensor; Doppler velocity logger
Mimics turtle; four
flapping rigid fins
for propulsion appended to a rigid
turtle-like hull; linearized engineering
control
Improvement in maneuverability by
reduction in stability; banked and
twisting turns (assisted by hull shape);
exceeds turning performance of AUV
by a factor of two;
minimum turn
radius D
0:7 times
body length
Not available
GhostSwimmer Boston
Engineering
Corp. [11.21]
Reconnaissance; hull
inspection; oceanographic mission
See Robotuna above Compact electronics
compared to that in
Robotuna
Dorsal, pectoral, and
caudal fins; flexible
body shaped as blue
fin tuna;
Small radius turning
ability
Efficient actuation
of flexible surface,
speed enhancement
MIT – Massachusetts Institute of Technology