

Highly Maneuverable Biorobotic Underwater Vehicles 11.3 Description of Biology-Inspired Vehicles of Emergent Maturity 291
Part B | 11.3
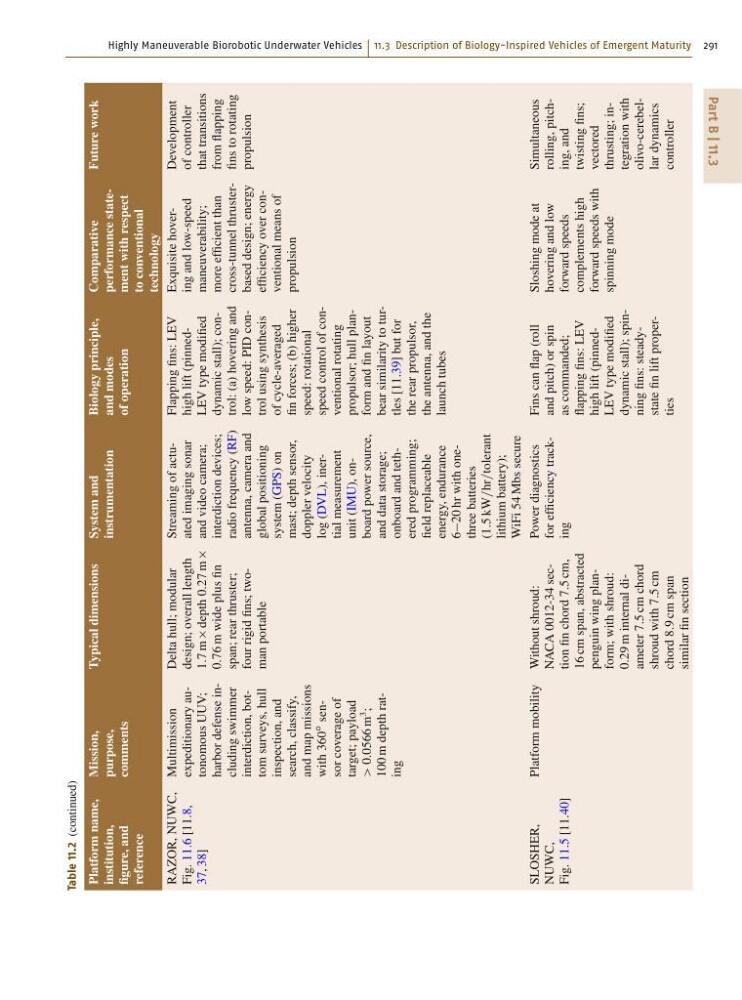
Table 11.2
(continued)
Platform name,
institution,
figure, and
reference
Mission,
purpose,
comments
Typical dimensions
System and
instrumentation
Biology principle,
and modes
of operation
Comparative
performance statement with respect
to conventional
technology
Future work
RAZOR, NUWC,
Fig. 11.6 [11.8,
37, 38]
Multimission
expeditionary autonomous UUV;
harbor defense including swimmer
interdiction, bottom surveys, hull
inspection, and
search, classify,
and map missions
with 360
ı
sensor coverage of
target; payload
> 0:0566 m
3
;
100 m depth rating
Delta hull; modular
design; overall length
1:7 m
depth 0:27 m
0:76 m wide plus fin
span; rear thruster;
four rigid fins; twoman portable
Streaming of actuated imaging sonar
and video camera;
interdiction devices;
radio frequency (RF)
antenna, camera and
global positioning
system (GPS) on
mast; depth sensor,
doppler velocity
log (DVL), inertial measurement
unit (IMU), onboard power source,
and data storage;
onboard and tethered programming;
field replaceable
energy, endurance
620 hr with onethree batteries
(1:5 kW=hr=tolerant
lithium battery);
WiFi 54 Mbs secure
Flapping fins: LEV
high lift (pinnedLEV type modified
dynamic stall); control: (a) hovering and
low speed: PID control using synthesis
of cycle-averaged
fin forces; (b) higher
speed: rotational
speed control of conventional rotating
propulsor; hull planform and fin layout
bear similarity to turtles [11.39] but for
the rear propulsor,
the antenna, and the
launch tubes
Exquisite hovering and low-speed
maneuverability;
more efficient than
cross-tunnel thrusterbased design; energy
efficiency over conventional means of
propulsion
Development
of controller
that transitions
from flapping
fins to rotating
propulsion
SLOSHER,
NUWC,
Fig. 11.5 [11.40]
Platform mobility Without shroud:
NACA 0012-34 section fin chord 7:5 cm,
16 cm span, abstracted
penguin wing planform; with shroud:
0:29 m internal diameter 7:5 cm chord
shroud with 7:5 cm
chord 8:9 cm span
similar fin section
Power diagnostics
for efficiency tracking
Fins can flap (roll
and pitch) or spin
as commanded;
flapping fins: LEV
high lift (pinnedLEV type modified
dynamic stall); spinning fins: steadystate fin lift properties
Sloshing mode at
hovering and low
forward speeds
complements high
forward speeds with
spinning mode
Simultaneous
rolling, pitching, and
twisting fins;
vectored
thrusting; integration with
olivo-cerebellar dynamics
controller