

Part A | 10.5
272 Part A Fundamentals
Similar conclusions hold for transfer function Q
G Y .s/,
too.
Example 10.7 Autopilot Steering System for Disturbance Rejection
A 6200 TEU container carrier will be examined as
typical application of the analysis and methodology developed for autopilot pole placement design earlier. The
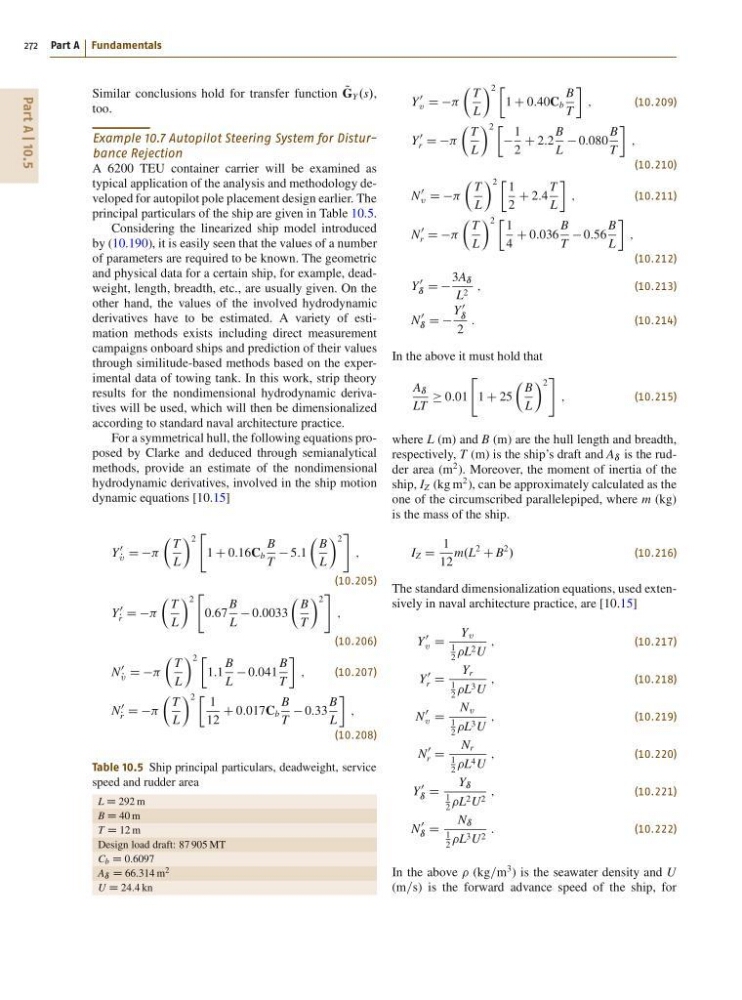
principal particulars of the ship are given in Table 10.5.
Considering the linearized ship model introduced
by (10.190), it is easily seen that the values of a number
of parameters are required to be known. The geometric
and physical data for a certain ship, for example, deadweight, length, breadth, etc., are usually given. On the
other hand, the values of the involved hydrodynamic
derivatives have to be estimated. A variety of estimation methods exists including direct measurement
campaigns onboard ships and prediction of their values
through similitude-based methods based on the experimental data of towing tank. In this work, strip theory
results for the nondimensional hydrodynamic derivatives will be used, which will then be dimensionalized
according to standard naval architecture practice.
For a symmetrical hull, the following equations proposed by Clarke and deduced through semianalytical
methods, provide an estimate of the nondimensional
hydrodynamic derivatives, involved in the ship motion
dynamic equations [10.15]
Y
0
P
v D D
 T
L
à 2
"
1 C 0:16C b
B
T
5:1
 B
L
à 2
#
;
(10.205)
Y
0
P r D D
 T
L
à 2
"
0:67
B
L
0:0033
 B
T
à 2
#
;
(10.206)
N
0
P
v D D
 T
L
à 2 Ä
1:1
B
L
0:041
B
T
;
(10.207)
N
0
P r D D
 T
L
à 2 Ä 1
12
C 0:017C b
B
T
0:33
B
L
;
(10.208)
Table 10.5 Ship principal particulars, deadweight, service
speed and rudder area
L D 292 m
B D 40 m
T D 12 m
Design load draft: 87 905 MT
C b D 0:6097
A ı D 66:314 m 2
U D 24:4 kn
Y
0
v D D
 T
L
à 2 Ä
1 C 0:40C b
B
T
;
(10.209)
Y
0
r D D
 T
L
à 2 Ä
1
2
C 2:2
B
L
0:080
B
T
;
(10.210)
N
0
v D D
 T
L
à 2 Ä 1
2
C 2:4
T
L
;
(10.211)
N
0
r D D
 T
L
à 2 Ä 1
4
C 0:036
B
T
0:56
B
L
;
(10.212)
Y
0
ı D D
3A ı
L 2 ;
(10.213)
N
0
ı D D
Y
0
ı
2
:
(10.214)
In the above it must hold that
A ı
LT
0:01
"
1 C 25
Â
B
L
à 2
#
;
(10.215)
where L (m) and B (m) are the hull length and breadth,
respectively, T (m) is the ship’s draft and A ı is the rudder area (m
2 ). Moreover, the moment of inertia of the
ship, I Z (kg m
2 ), can be approximately calculated as the
one of the circumscribed parallelepiped, where m (kg)
is the mass of the ship.
I Z D
1
12
m.L
2
C B
2
/
(10.216)
The standard dimensionalization equations, used extensively in naval architecture practice, are [10.15]
Y
0
v D
Y v
1
2
L 2 U
;
(10.217)
Y
0
r D
Y r
1
2
L 3 U
;
(10.218)
N
0
v D
N v
1
2
L 3 U
;
(10.219)
N
0
r D
N r
1
2
L 4 U
;
(10.220)
Y
0
ı D
Y ı
1
2
L 2 U 2 ;
(10.221)
N
0
ı D
N ı
1
2
L 3 U 2
:
(10.222)
In the above (kg=m
3 ) is the seawater density and U
(m=s) is the forward advance speed of the ship, for