

Control Theory and Applications 10.2 Analysis of LTI Systems 237
Part A | 10.2
vehicle and propeller speed. Despite the significant
assumption used in the forward speed model, its mathematical equations remain highly nonlinear.
Based on the results obtained in the previous example, the forward speed model can be linearized to
M P
u C d fu 0 ju 0 j C 2 ju 0 j .u u 0 /g
D c T f˝ 0 j˝ 0 j C 2 j˝ 0 j .˝ ˝ 0 /g
P
˝ D ˇˇ ˛ f˝ 0 j˝ 0 j C 2 j˝ 0 j .˝ ˝ 0 /g
9
> =
> ;
)
)
8
ˆ <
ˆ :
M P
u C 2d ju 0 j u D 2c T ˝ j˝ 0 j C du 0 ju 0 j
c T ˝ 0 j˝ 0 j
P
˝ C 2˛˝ j˝ 0 j D ˇˇ C ˛˝ 0 j˝ 0 j
:
(10.57)
These linearized equations can be further simplified if
the point of linearization is also the equilibrium point.
That is, choose u 0 , ˝ 0 , such that P
u D 0, or
du 0 ju 0 j D c T ˝ 0 j˝ 0 j :
The simplified forward speed model can then be expressed as
M P
u C 2d ju 0 j u D 2c T ˝ j˝ 0 j ;
P
˝ C 2˛˝ j˝ 0 j D ˇˇ C ˛˝ 0 j˝ 0 j :
(10.58)
It should be noted that the term ˛˝ 0 j˝ 0 j can be treated
as a fictitious input that drives the propeller speed based
on the point of linearization.
10.2 Analysis of LTI Systems
10.2.1 Block Diagrams
The block diagram of a system serves as a depiction
of the interconnection structure of the various subsystems as well as the signals circulation and traffic. Each
sub-block of the overall block diagram is defined by an
input–output (I/O) relationship, which for LTI systems
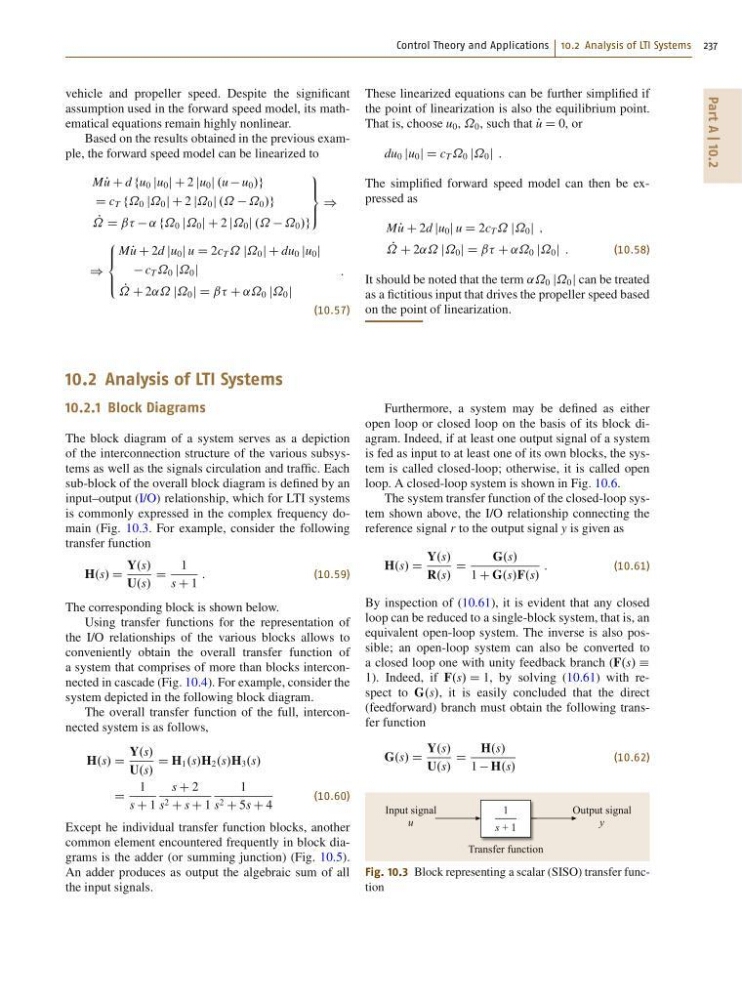
is commonly expressed in the complex frequency domain (Fig. 10.3. For example, consider the following
transfer function
H.s/ D
Y.s/
U.s/
D
1
s C 1
:
(10.59)
The corresponding block is shown below.
Using transfer functions for the representation of
the I/O relationships of the various blocks allows to
conveniently obtain the overall transfer function of
a system that comprises of more than blocks interconnected in cascade (Fig. 10.4). For example, consider the
system depicted in the following block diagram.
The overall transfer function of the full, interconnected system is as follows,
H.s/ D
Y.s/
U.s/
D H 1 .s/H 2 .s/H 3 .s/
D
1
s C 1
s C 2
s 2 C s C 1
1
s 2 C 5s C 4
(10.60)
Except he individual transfer function blocks, another
common element encountered frequently in block diagrams is the adder (or summing junction) (Fig. 10.5).
An adder produces as output the algebraic sum of all
the input signals.
Furthermore, a system may be defined as either
open loop or closed loop on the basis of its block diagram. Indeed, if at least one output signal of a system
is fed as input to at least one of its own blocks, the system is called closed-loop; otherwise, it is called open
loop. A closed-loop system is shown in Fig. 10.6.
The system transfer function of the closed-loop system shown above, the I/O relationship connecting the
reference signal r to the output signal y is given as
H.s/ D
Y.s/
R.s/
D
G.s/
1 C G.s/F.s/
:
(10.61)
By inspection of (10.61), it is evident that any closed
loop can be reduced to a single-block system, that is, an
equivalent open-loop system. The inverse is also possible; an open-loop system can also be converted to
a closed loop one with unity feedback branch (F.s/ Á
1). Indeed, if F.s/ D 1, by solving (10.61) with respect to G.s/, it is easily concluded that the direct
(feedforward) branch must obtain the following transfer function
G.s/ D
Y.s/
U.s/
D
H.s/
1 H.s/
(10.62)
Output signal
y
Transfer function
Input signal
u
1
s + 1
Fig. 10.3 Block representing a scalar (SISO) transfer function