

Part A | 8.6
186 Part A Fundamentals
for all angles of incidence. This produces the values
s D 1, D 0, and q D ˇ from (8.77) and (8.83). The
electromagnetic wave’s angle of refraction in the ocean,
given by (8.89), reduces to
« D tan
1
 !
cˇ
sin  i
Ã
:
(8.91)
At 1 Hz,
!
cˇ
D 5:27 10
6 , and the maximum angle
of refraction is « max Ä tan
1
.5:27 10
6
/ or « max Ä
3 10
4ı ( 1 s of an arc). Even at 3 kHz the refracted
angle is computed to be less than 0:02
ı . Therefore, for
frequencies up through the ELF band, a plane wave
incident on the surface of the ocean at any angle will refract, propagate, and attenuate toward the bottom along
a path that is nearly vertical.
The analysis presented above for a single interface can be extended to include any number of layers
with different intrinsic parameters. The derivation of
the iterative equation can be found in [8.2, pp. 110–
120]. Plane wave reflection and transmission for multilayered ocean environments would arise when modeling depth variations of uniformly stratified seawater or
seafloor conductivities.
8.6 Magnetic and Electric Dipoles in an Unbounded Ocean
Strictly speaking, plane waves do not exist in nature.
They can be used to approximate an electromagnetic
field that is far from its source (transmitter), or in the
case where a uniform distribution of sources extend
to very large distances in comparison to the receiver’s
range to it. An example of the latter case would be
the geomagnetic fields present at the ocean’s surface
generated by solar-wind-induced electric currents in the
ionosphere.
The two elemental sources of electromagnetic fields
are the electric and magnetic point dipoles. An electric
dipole source p is created by an electric current I flowing in a conductor over a linear distance l (p D Il/, and
has units of A m. A magnetic dipole m is produced if the
current flows around a closed circular path that encloses
an area a (m D Ia/, and has units of A m
2 . If the observation point is at a distance that is large compared to the
source’s dimensions, then it can be represented mathematically as an infinitesimally small or point dipole.
With sources present, the time-harmonic vector wave
equations, (8.27) and (8.28), are now inhomogeneous.
Although it is possible to solve for the electric and
magnetic fields directly from the inhomogeneous vector
wave equations, it is generally mathematically advantageous to replace them with equivalent representations
in terms of the magnetic vector potential A and electric
vector potential F. The solutions to the inhomogeneous
vector wave equations in terms of vector potentials are
derived in [8.3], and can be written as
E D Di!A C
1
r.r r A/
1
"
r r F ;
(8.92)
H D Di!F C
1
r.r r F/ C
1
r r A ;
(8.93)
where
A D
4
•
V
J i
e
R
R
dv
0
;
(8.94)
F D
"
4
•
V
M i
e
R
R
dv
0
;
(8.95)
R D
q
.x x
0 / 2 C .y y
0 / 2 C .z z
0 / 2 ;
(8.96)
and the elements of the impressed electric J i and magnetic M i current densities are located at .x
0 ; y
0 ; z
0
/ with
the observation point at .x; y; z/. The integration is taken
over the entire volume of the source.
Equations (8.92)–(8.96) are sufficient to compute
the electric and magnetic fields from dipole sources.
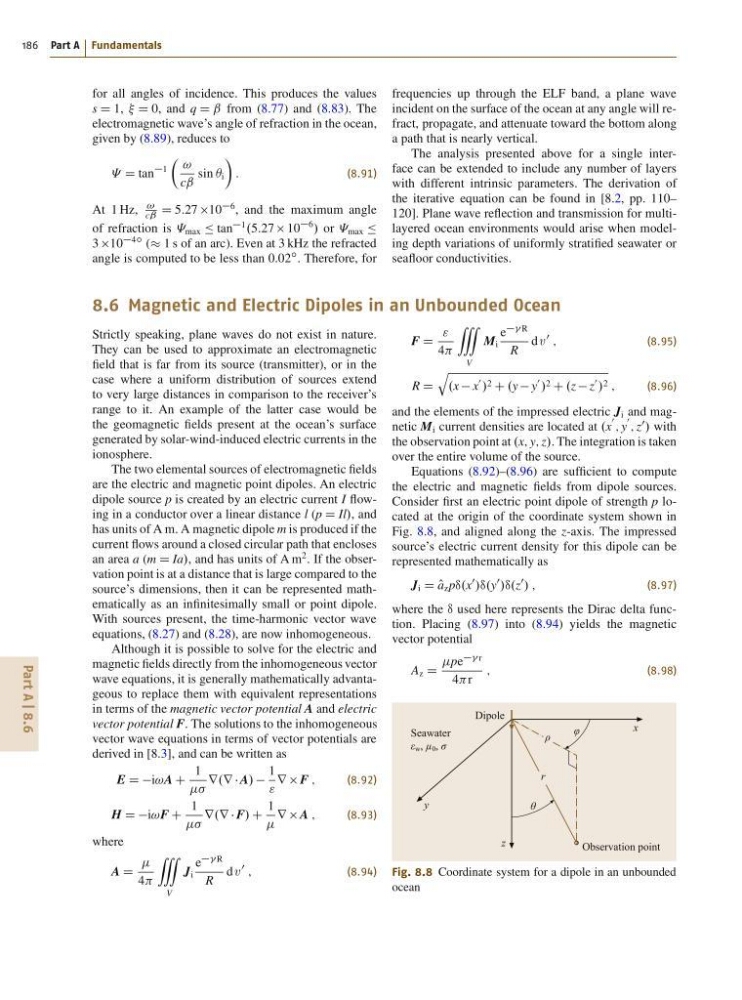
Consider first an electric point dipole of strength p located at the origin of the coordinate system shown in
Fig. 8.8, and aligned along the z-axis. The impressed
source’s electric current density for this dipole can be
represented mathematically as
J i D O
a z p•.x
0
/•.y
0
/•.z
0
/ ;
(8.97)
where the • used here represents the Dirac delta function. Placing (8.97) into (8.94) yields the magnetic
vector potential
A z D
pe
r
4r
;
(8.98)
x
y
r
z
Seawater
ε w , μ 0 , σ
Dipole
Observation point
θ
ρ
φ
Fig. 8.8 Coordinate system for a dipole in an unbounded
ocean