

216
Air Pollution and Turbulence: Modeling and Applications
dispersion modeling are the input fl ow and turbulence fi elds, namely, the mean wind
fi eld, turbulence parameters, surface-layer parameters, and the height of the atmospheric boundary layer. In particular, in 3-D dispersion studies and in complex terrain, it is of great importance to also take into account the spatial variations of wind
velocity moments and therefore the complete 3-D structure of the turbulent fl ow
must be considered.
Flow fi eld is generally obtained by meteorological (prognostic) or mass-consistent
(diagnostic) models. The latter is built to include observed values too, and prognostic
models also can deal with observations through data assimilation techniques. As far as
the problem of prescribing the input turbulence fi elds is concerned, these quantities can
be inferred directly from the meteorological model outputs, if that model solves a turbulent kinetic energy equation, or they can be derived from empirical parameterizations
based upon both the available measurements and PBL theory. The parameterization
schemes prescribed by Hanna (1982) and by Degrazia et al. (2000) are good examples
of these parameterizations. These schemes do not include estimations of the skewness
of the vertical wind velocity that, as above mentioned, are essential in the simulation of
the convective boundary layer. They can be parameterized according to, for instance,
Chiba (1978), De Baas et al. (1986), Weil (1990), and Rotach et al. (1996).
8.7.2 BOUNDARY CONDITIONS
In the LSDMs, the simplest and widely used boundary condition is the so-called
perfect refl ection: when a particle bumps against a boundary (upper or lower), it
leaves the boundary in the opposite direction with the same vertical velocity and
reversed sign. However, for skewed (non-Gaussian) turbulence, this may lead to an
accumulation or defi cit of particles at the boundaries.
The correct method of dealing with this problem was stated by Thomson and
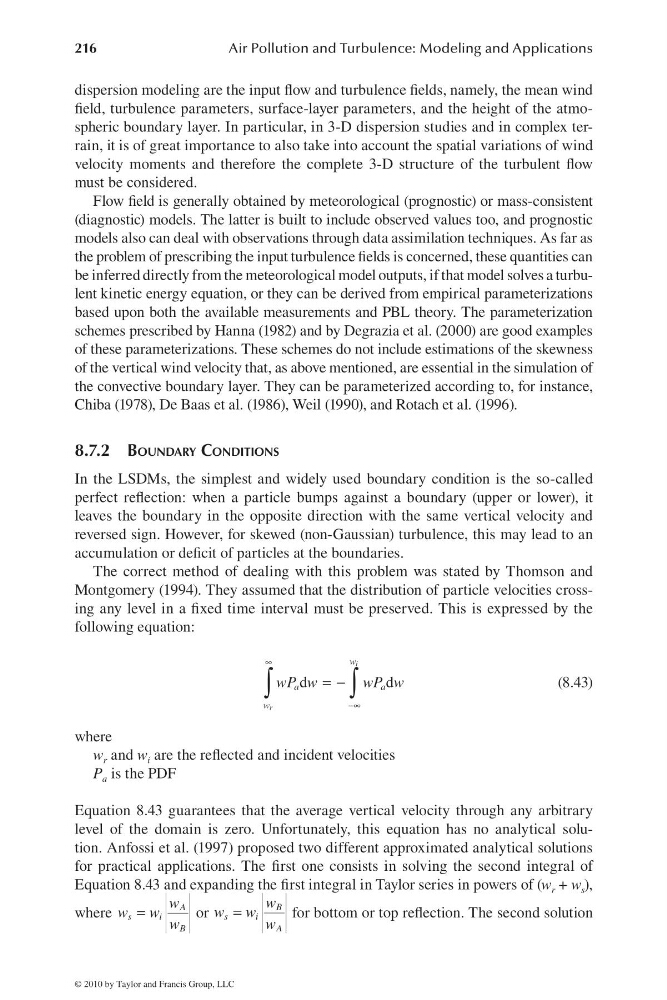
Montgomery (1994). They assumed that the distribution of particle velocities crossing any level in a fi xed time interval must be preserved. This is expressed by the
following equation:
d
d
i
r
w
a
a
w
wP w
wP w
∞
−∞
= −
∫
∫
(8.43)
where
w r and w i are the refl ected and incident velocities
P a is the PDF
Equation 8.43 guarantees that the average vertical velocity through any arbitrary
level of the domain is zero. Unfortunately, this equation has no analytical solution. Anfossi et al. (1997) proposed two different approximated analytical solutions
for practical applications. The fi rst one consists in solving the second integral of
Equation 8.43 and expanding the fi rst integral in Taylor series in powers of (w r + w s ),
where
A
s
i
B
w
w w
w
=
or
B
s
i
A
w
w w
w
=
for bottom or top refl ection. The second solution
© 2010 by Taylor and Francis Group, LLC