

8-3 Perspective mapping equations 253
Box 8.10 (Computational products).
X c = X 0 + H 0 n ,
X P − X c
2 =
˙
X P − X 0 − H 0 n
˛
˛ X P − X 0 − H 0 n
¸
=
= X P − X 0
2 −2H 0
˙
X P − X 0
˛
˛ n
¸
+ H
2
0 ,
˙
X P − X c
˛
˛ n
¸ 2 =
˙
X P − X 0 − H 0 n
˛
˛ n
¸ 2 =
`˙
X P − X 0
˛
˛ n
¸ − H 0
´ 2 =
=
`˙
X P − X 0
˛
˛ n
¸´ 2 − 2H 0
˙
X P − X 0
˛
˛ n
¸
+ H
2
0
⇒
X P − X c
2 −
˙
X P − X c
˛
˛ n
¸ 2 = X P − X 0
2 −
˙
X P − X 0
˛
˛ n
¸ 2
⇒
r = H 0
q
X P − X 0 2 −
˙
X P − X 0
˛
˛ n
¸ 2
˛
˛
˙
X P − X 0
˛
˛ n
¸ − H 0
˛
˛
.
(8.112)
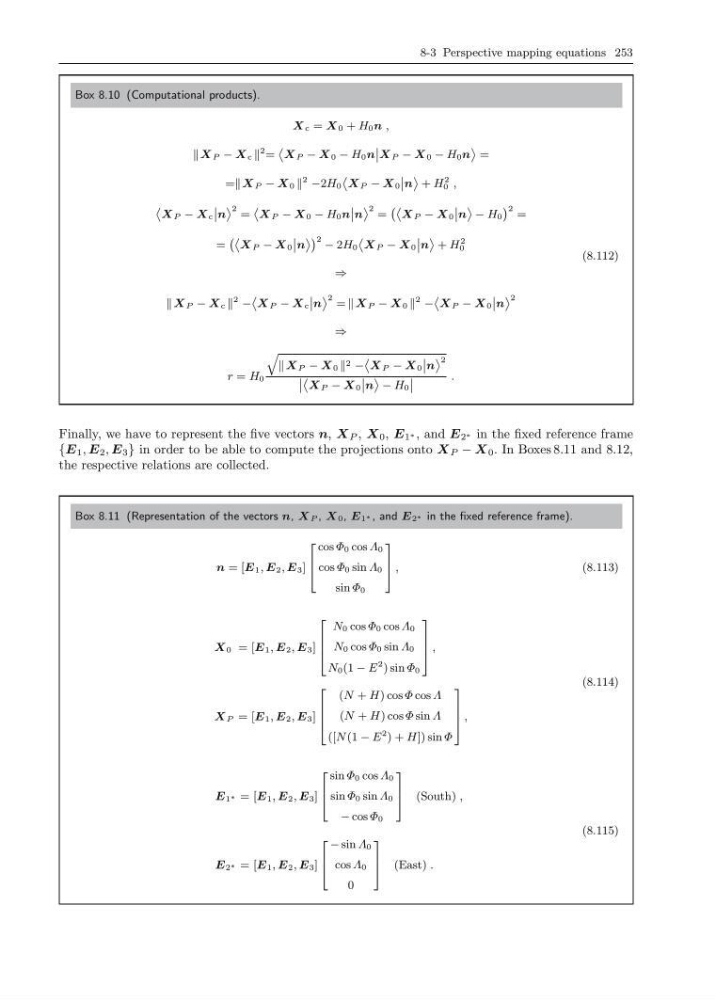
Finally, we have to represent the five vectors n, X P , X 0 , E 1 ∗ , and E 2 ∗ in the fixed reference frame
{E 1 , E 2 , E 3 } in order to be able to compute the projections onto X P − X 0 . In Boxes 8.11 and 8.12,
the respective relations are collected.
Box 8.11 (Representation of the vectors n, X P , X 0 , E 1 ∗ , and E 2 ∗ in the fixed reference frame).
n = [E 1 , E 2 , E 3 ]
2
6
4
cos Φ 0 cos Λ 0
cos Φ 0 sin Λ 0
sin Φ 0
3
7
5 ,
(8.113)
X 0 = [E 1 , E 2 , E 3 ]
2
6
6
4
N 0 cos Φ 0 cos Λ 0
N 0 cos Φ 0 sin Λ 0
N 0 (1 − E
2 ) sin Φ 0
3
7
7
5 ,
X P = [E 1 , E 2 , E 3 ]
2
6
6
4
(N + H) cos Φ cos Λ
(N + H) cos Φ sin Λ
([N (1 − E
2 ) + H]) sin Φ
3
7
7
5 ,
(8.114)
E 1 ∗ = [E 1 , E 2 , E 3 ]
2
6
4
sin Φ 0 cos Λ 0
sin Φ 0 sin Λ 0
− cos Φ 0
3
7
5 (South) ,
E 2 ∗ = [E 1 , E 2 , E 3 ]
2
6
4
− sin Λ 0
cos Λ 0
0
3
7
5 (East) .
(8.115)