

3-2 Killing vectors of symmetry 123
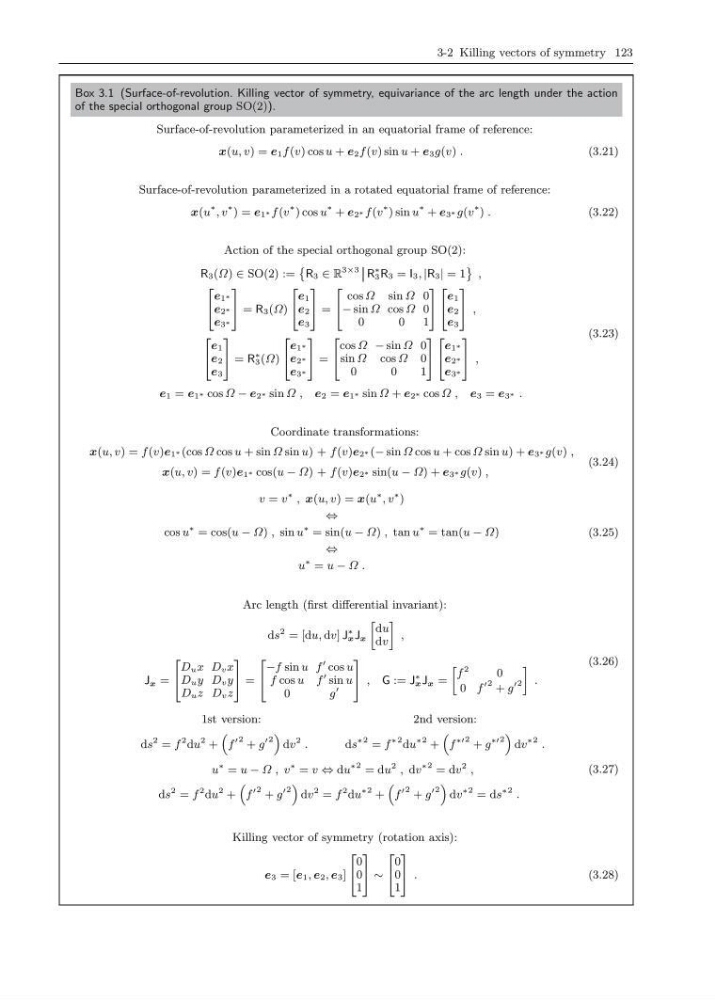
Box 3.1 (Surface-of-revolution. Killing vector of symmetry, equivariance of the arc length under the action
of the special orthogonal group SO(2)).
Surface-of-revolution parameterized in an equatorial frame of reference:
x(u, v) = e 1 f (v) cos u + e 2 f (v) sin u + e 3 g(v) .
(3.21)
Surface-of-revolution parameterized in a rotated equatorial frame of reference:
x(u
∗ , v
∗ ) = e 1 ∗ f (v
∗ ) cos u
∗ + e 2 ∗ f (v
∗ ) sin u
∗ + e 3 ∗ g(v
∗ ) .
(3.22)
Action of the special orthogonal group SO(2):
R 3 (Ω) ∈ SO(2) :=
˘
R 3 ∈ R
3×3 R
∗
3 R 3 = I 3 , |R 3 | = 1
¯
,
2
4
e 1 ∗
e 2 ∗
e 3 ∗
3
5 = R 3 (Ω)
2
4
e 1
e 2
e 3
3
5 =
2
4
cos Ω sin Ω 0
− sin Ω cos Ω 0
0
0
1
3
5
2
4
e 1
e 2
e 3
3
5 ,
2
4
e 1
e 2
e 3
3
5 = R
∗
3 (Ω)
2
4
e 1 ∗
e 2 ∗
e 3 ∗
3
5 =
2
4
cos Ω − sin Ω 0
sin Ω cos Ω 0
0
0
1
3
5
2
4
e 1 ∗
e 2 ∗
e 3 ∗
3
5 ,
e 1 = e 1 ∗ cos Ω − e 2 ∗ sin Ω , e 2 = e 1 ∗ sin Ω + e 2 ∗ cos Ω , e 3 = e 3 ∗ .
(3.23)
Coordinate transformations:
x(u, v) = f (v)e 1 ∗ (cos Ω cos u + sin Ω sin u) + f (v)e 2 ∗ (− sin Ω cos u + cos Ω sin u) + e 3 ∗ g(v) ,
x(u, v) = f (v)e 1 ∗ cos(u − Ω) + f (v)e 2 ∗ sin(u − Ω) + e 3 ∗ g(v) ,
(3.24)
v = v
∗ , x(u, v) = x(u
∗ , v
∗ )
⇔
cos u
∗ = cos(u − Ω) , sin u
∗ = sin(u − Ω) , tan u
∗ = tan(u − Ω)
⇔
u
∗ = u − Ω .
(3.25)
Arc length (first differential invariant):
ds
2 = [du, dv] J
∗
x J x
»
du
dv
–
,
J x =
2
4
D u x D v x
D u y D v y
D u z D v z
3
5 =
2
4
−f sin u f
cos u
f cos u f
sin u
0
g
3
5 , G := J
∗
x J x =
»
f
2
0
0 f
2 + g
2
–
.
(3.26)
1st version:
2nd version:
ds
2 = f
2 du
2 +
“
f
2 + g
2
”
dv
2 .
ds
∗2 = f
∗2 du
∗2 +
“
f
∗∗2 + g
∗∗2
”
dv
∗2 .
u
∗ = u − Ω , v
∗ = v ⇔ du
∗2 = du
2 , dv
∗2 = dv
2 ,
ds
2 = f
2 du
2 +
“
f
+ g
”
dv
2 = f
2 du
∗2 +
“
f
+ g
”
dv
∗2 = ds
∗2 .
(3.27)
Killing vector of symmetry (rotation axis):
e 3 = [e 1 , e 2 , e 3 ]
2
4
0
0
1
3
5 ∼
2
4
0
0
1
3
5 .
(3.28)