

226
7. Mathematical Models of Groundwater Quality
ac;aÄ, etc. To calculate these derivatives, the simplest way is still the use of
finite difference approximations. To improve the convergence of the GaussNewton method, the following iteration series is often used:
(7.3.18)
where L\Pr is determined from Eq. (7.3.16) and Ä r by one-dimensional
optimization. In addition, by controlling the value of Ä r or using Rosen's
projection method, the solutions can satisfy the given constraints.
More optimization methods for solving inverse problems in groundwater
modeling can be found in Sun (1981), Yeh (1986), Carrera (1987), and Sun
(1994). The coupled inverse problem of flow and mass transport was considered by Carrera (1987) and Wagner and Gorelick (1987), where the unknown
transmissivities and dispersivities are determined simultaneously. Ewing et
al. (1987) described a coupled inverse problem in connection with the simulation ofsecondary recovery processes in oil reservoirs. Woodbury et al. (1987),
and Woodbury and Smith (1988), used temperature measurement to improve
the estimation of hydraulic conductivities, in which the inverse problem of
flow-heat transport was solved. Mishra and Parker (1989) considered the
inverse problem for coupled unsaturated flow and mass transportation. A
complete description of coupled inverse problems in groundwater modeling
was given by Sun and Yeh (1990a, b). Xiang et al. (1993) used Li-norm
criterion to solve coupled inverse problems of groundwater flow and mass
transport. A program that can solve coupled inverse problems of groundwater flow and mass transport by a modified Gauss-Newton method is given
in Sun (1994).
7.3.2 Variational Sensitivity Analysis
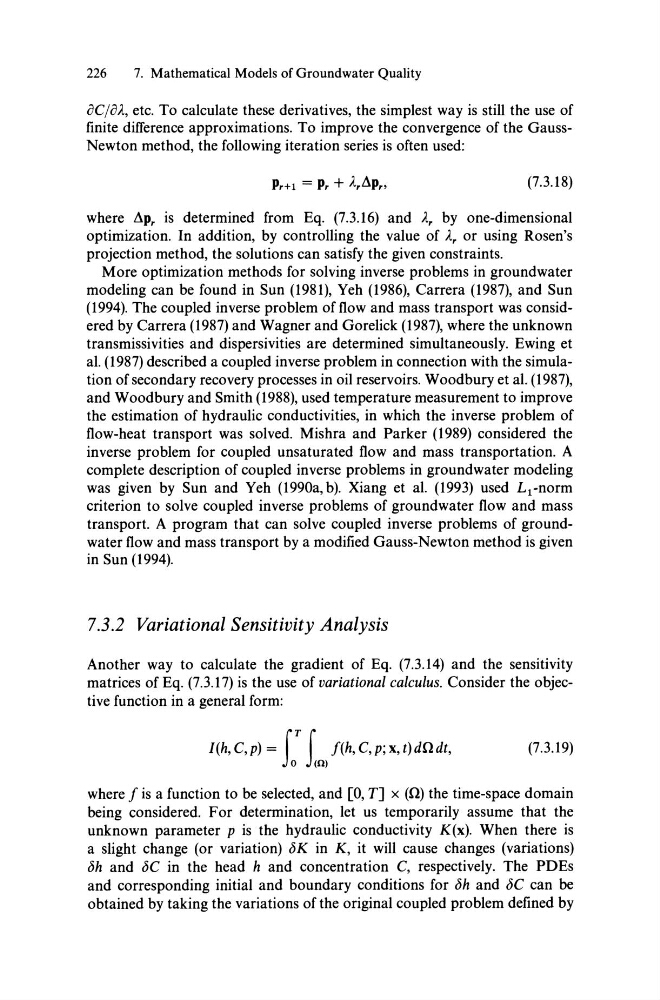
Another way to calculate the gradient of Eq. (7.3.14) and the sensitivity
matrices of Eq. (7.3.17) is the use of variational calculus. Consider the objective function in a general form:
I(h,C,p) = fT f j(h,C,p;x,t)dQdt,
Jo JO)
(7.3.19)
where j is a function to be selected, and [0, T] x (Q) the time-space domain
being considered. For determination, let us temporarily assurne that the
unknown parameter p is the hydraulic conductivity K(x). When there is
a slight change (or variation) oK in K, it will cause changes (variations)
oh and OC in the head hand concentration C, respectively. The PDEs
and corresponding initial and boundary conditions for oh and OC can be
obtained by taking the variations of the original coupled problem defined by