

152
6. Numerical Solutions of Advection-Dominated Problems
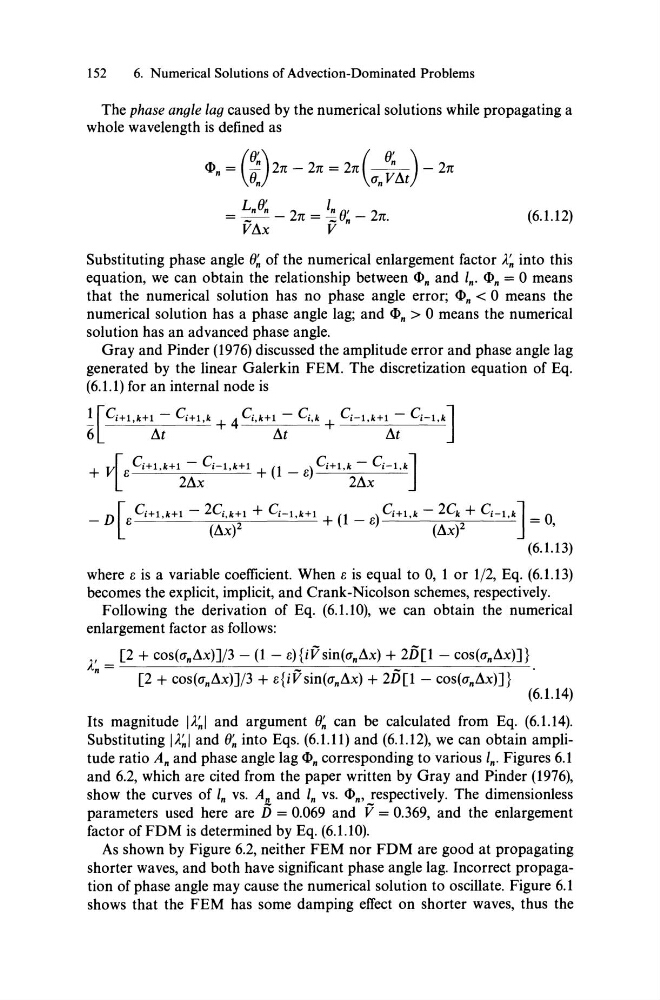
The phase angle lag caused by the numerical solutions while propagating a
whole wavelength is defined as
Ibn = (~) 2n - 2n = 2n (~) - 2n
(}n
(J' n V~t
= :n(}~ _ 2n = ~(}~ - 2n.
V~x
V
(6.1.12)
Substituting phase angle (}~ of the numerical enlargement factor A.~ into this
equation, we can obtain the relationship between Ibn and In. Ibn = 0 means
that the numerical solution has no phase angle error; Ib" < 0 means the
numerical solution has a phase angle lag; and Ib" > 0 means the numerical
solution has an advanced phase angle.
Gray and Pinder (1976) discussed the amplitude error and phase angle lag
generated by the linear Galerkin FEM. The discretization equation of Eq.
(6.1.1) for an internal node is
~[Ci+l'k+l - Ci+l,k + 4 Ci,k+l - Ci,k + Ci-l,k+l - Ci-l,k]
6
~t
~t
~t
{
Ci+l k+l - C i- l k+l
(1
) Ci+l k - C i- l k]
+ 1 : '
' + - I : '
,
2~x
2~x
_
[Ci+l'k+l - 2Ci,k+l + Ci-l,k+l (1 _ ) Ci+l,k - 2Ck + Ci-l,k] = 0
D I:
(~X)2
+
I:
(~X)2
'
(6.1.13)
where I: is a variable coefficient. When I: is equal to 0, 1 or 1/2, Eq. (6.1.13)
becomes the explicit, implicit, and Crank-Nicolson schemes, respectively.
Following the derivation of Eq. (6.1.10), we can obtain the numerical
enlargement factor as folIows:
A.~ = [2 + cos«(J'n~x)]/3 - (1 - l:)yvsin«(J'n~x) +_2D[1 - cos«(J'n~x)]}.
[2 + cos«(J'n~x)]/3 + l:{iVsin«(J',,~x) + 2D[1 - cos«(J'n~x)]}
(6.1.14)
Its magnitude IA.~I and argument (}~ can be calculated from Eq. (6.1.14).
Substituting IA.~I and (}~ into Eqs. (6.1.11) and (6.1.12), we can obtain amplitude ratio A" and phase angle lag Ib" corresponding to various I". Figures 6.1
and 6.2, which are cited from the paper written by Gray and Pinder (1976),
show the curves of I" vs. A" and I" vs. Ib", respectively. The dimensionless
parameters used here are D = 0.069 and V = 0.369, and the enlargement
factor of FDM is determined by Eq. (6.1.10).
As shown by Figure 6.2, neither FEM nor FDM are good at propagating
shorter waves, and both have significant phase angle lag. Incorrect propagation of phase angle may cause the numerical solution to oscillate. Figure 6.1
shows that the FEM has some damping effect on shorter waves, thus the