

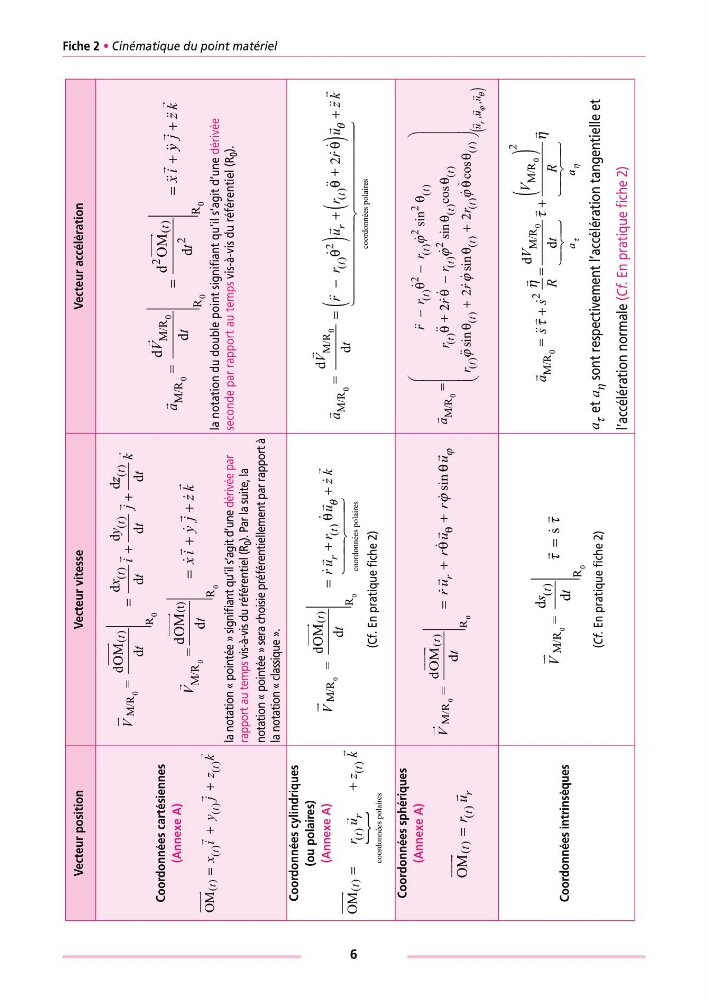
Fiche 2 • Cinématique du point matériel
Vecteur position
Vecteur vitesse
Vecteur accélération
Coordonnées cartésiennes
(Annexe A)
la notation « pointée » signifiant qu’il s’agit d’une dérivée par
rapport au temps vis-à-vis du référentiel (R
0 ). Par la suite, la
notation « pointée » sera choisie préférentiellement par rapport à
la notation « classique ».
la notation du double point signifiant qu’il s’agit d’une dérivée
seconde par rapport au temps vis-à-vis du référentiel (R
0 ).
Coordonnées cylindriques
(ou polaires)
(Annexe A)
(Cf. En pratique fiche 2)
Coordonnées sphériques
(Annexe A)
Coordonnées intrinsèques
(Cf. En pratique fiche 2)
et sont respectivement l’accélération tangentielle et
l’accélération normale (Cf. En pratique fiche 2)
OM
()
()
()
()
t
ttt
xi
yj zk
=+
+
V
t
x
t
i
y
t
j
tt
t
M/R
R
0
0
=
dOM
d
d
d
d
d
d
()
()
()
=++
z z
t
k
t()
d
V
t
xi yj zk
M/R
(t)
R
0
0
=
dOM
d
=++
a
V
t
t
xi
t
M/R
M/R
R
R
0
0
0
0
=
d
d
dO M
d
==
+
()
2
2
y y jz k
+
OM
coordonnées polaires
()
()
()
t
tr
t
ru
zk
=+
V
t
ru ru
t
rt
M/R
R
0
0
=
dOM
d
coord
()
()
=+
θ
θ
o o nnées polaires
+ zk
a
V
t
rr
ur
tr
t
M/R
M/R
2
0
0
=
d
d
()
()
=−
(
) +
θθ + +
coordonnées polaires
2
ru θ
(
) θ
+ zk
OM
()
()
t
tr
ru
=
V
t
ru
ru
r
t
r
M/R
R
0
0
=
dOM
d
()
sin
=
+
+
θ
θ
ϕ
θ θ
u
ϕ
a
rr
r
r
tt
t
t
M/R
22
0
=
+
−−
s in
()
()
()
()
θθ
θ
ϕ
2
2 2
2
rr
r
tt
t
tt
θθ
θ
θ
sin
()
()
()
()
()
−
+
s in
cos
2
ϕ
ϕ
rr
tt
t
u
r
ϕϕ sin
c os
()
()
()
,
θθ
θ
+
⎛
⎝
⎜
⎜
⎜
⎜
⎞
⎠
⎟
⎟
⎟
⎟
2
u u u
ϕθ ,
(
)
V
s
t
t
M/R
R
0
0
=
d
d
s
()
ττ =
as
s
R
V
t
V
R
a
M/R
M/R
M/R
0
0
0
==
d
d
τ
η
τ
τ
++
( )
2
2
a a
η
η
a
τ
a
η
6