

76
2 Particle Dynamics
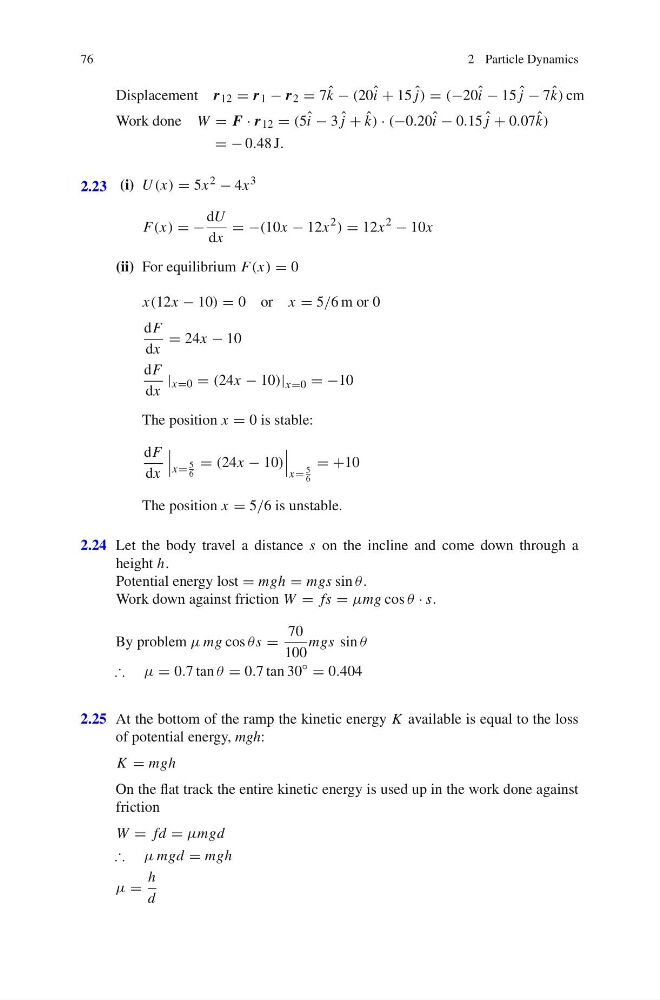
Displacement r 12 = r 1 − r 2 = 7 ˆ
k − (20 ˆ
i + 15 ˆ
j) = (−20 ˆ
i − 15 ˆ
j − 7 ˆ
k) cm
Work done W = F · r 12 = (5 ˆ
i − 3 ˆ
j + ˆ
k) · (−0.20 ˆ
i − 0.15 ˆ
j + 0.07 ˆ
k)
= − 0.48 J.
2.23 (i) U (x) = 5x 2 − 4x 3
F(x) = −
dU
dx
= −(10x − 12x
2
) = 12x
2
− 10x
(ii) For equilibrium F(x) = 0
x(12x − 10) = 0 or x = 5/6 m or 0
dF
dx
= 24x − 10
dF
dx
| x=0 = (24x − 10)| x=0 = −10
The position x = 0 is stable:
dF
dx
x=
5
6
= (24x − 10)
x=
5
6
= +10
The position x = 5/6 is unstable.
2.24 Let the body travel a distance s on the incline and come down through a
height h.
Potential energy lost = mgh = mgs sin θ .
Work down against friction W = fs = μmg cos θ · s.
By problem μ mg cos θ s =
70
100
mgs sin θ
∴ μ = 0.7 tan θ = 0.7 tan 30
◦
= 0.404
2.25 At the bottom of the ramp the kinetic energy K available is equal to the loss
of potential energy, mgh:
K = mgh
On the flat track the entire kinetic energy is used up in the work done against
friction
W = fd = μmgd
∴ μ mgd = mgh
μ =
h
d