

11.5 State Equations and Nonlinear Dynamics
407
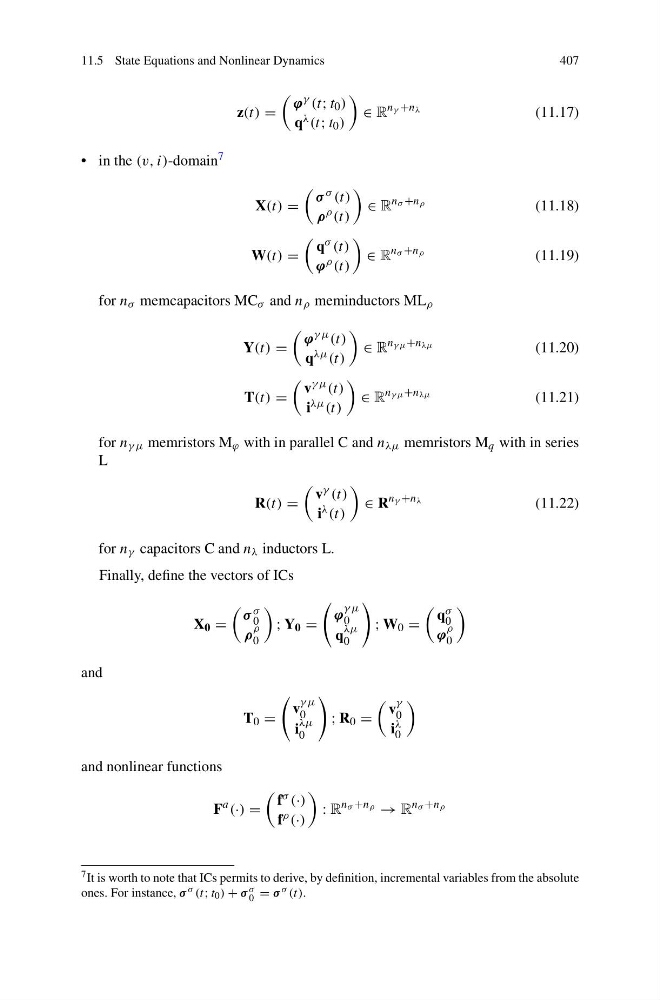
z(t) =
ϕ γ (t; t 0 )
q λ (t; t 0 )
∈ R
n γ +n λ
(11.17)
• in the (v, i)-domain 7
X(t) =
σ σ (t)
ρ ρ (t)
∈ R
n σ +n ρ
(11.18)
W(t) =
q σ (t)
ϕ ρ (t)
∈ R
n σ +n ρ
(11.19)
for n σ memcapacitors MC σ and n ρ meminductors ML ρ
Y(t) =
ϕ γ μ (t)
q λμ (t)
∈ R
n γ μ +n λμ
(11.20)
T(t) =
v γ μ (t)
i λμ (t)
∈ R
n γ μ +n λμ
(11.21)
for n γ μ memristors M ϕ with in parallel C and n λμ memristors M q with in series
L
R(t) =
v γ (t)
i λ (t)
∈ R
n γ +n λ
(11.22)
for n γ capacitors C and n λ inductors L.
Finally, define the vectors of ICs
X 0 =
σ σ
0
ρ
ρ
0
; Y 0 =
ϕ
γ μ
0
q
λμ
0
; W 0 =
q σ
0
ϕ
ρ
0
and
T 0 =
v
γ μ
0
i
λμ
0
; R 0 =
v
γ
0
i λ
0
and nonlinear functions
F
a (·) =
f σ (·)
f ρ (·)
: R
n σ +n ρ → R
n σ +n ρ
7 It is worth to note that ICs permits to derive, by definition, incremental variables from the absolute
ones. For instance, σ σ (t; t 0 ) + σ σ
0 = σ σ (t).