

286
7 Pulse Programming of Memristor Circuits
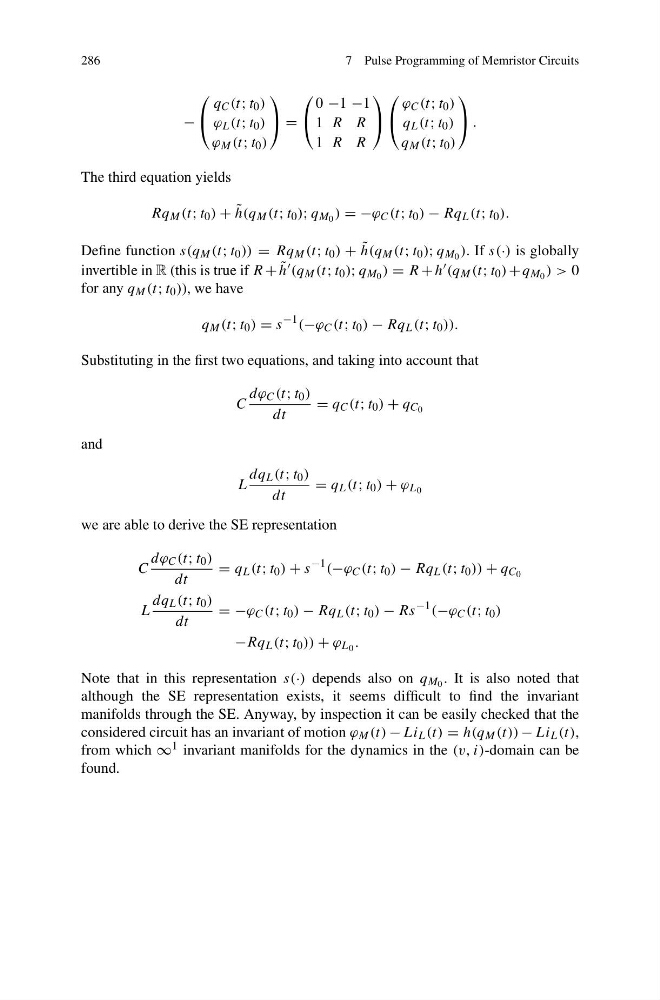
−
⎛
⎝
q C (t; t 0 )
ϕ L (t; t 0 )
ϕ M (t; t 0 )
⎞
⎠ =
⎛
⎝
0 −1 −1
1 R R
1 R R
⎞
⎠
⎛
⎝
ϕ C (t; t 0 )
q L (t; t 0 )
q M (t; t 0 )
⎞
⎠ .
The third equation yields
Rq M (t; t 0 ) + ˜
h(q M (t; t 0 ); q M 0 ) = −ϕ C (t; t 0 ) − Rq L (t; t 0 ).
Define function s(q M (t; t 0 )) = Rq M (t; t 0 ) + ˜
h(q M (t; t 0 ); q M 0 ). If s(·) is globally
invertible in R (this is true if R + ˜
h (q M (t; t 0 ); q M 0 ) = R + h (q M (t; t 0 ) + q M 0 ) > 0
for any q M (t; t 0 )), we have
q M (t; t 0 ) = s
−1 (−ϕ C (t; t 0 ) − Rq L (t; t 0 )).
Substituting in the first two equations, and taking into account that
C
dϕ C (t; t 0 )
dt
= q C (t; t 0 ) + q C 0
and
L
dq L (t; t 0 )
dt
= q L (t; t 0 ) + ϕ L 0
we are able to derive the SE representation
C
dϕ C (t; t 0 )
dt
= q L (t; t 0 ) + s
−1 (−ϕ C (t; t 0 ) − Rq L (t; t 0 )) + q C 0
L
dq L (t; t 0 )
dt
= −ϕ C (t; t 0 ) − Rq L (t; t 0 ) − Rs
−1 (−ϕ C (t; t 0 )
−Rq L (t; t 0 )) + ϕ L 0 .
Note that in this representation s(·) depends also on q M 0 . It is also noted that
although the SE representation exists, it seems difficult to find the invariant
manifolds through the SE. Anyway, by inspection it can be easily checked that the
considered circuit has an invariant of motion ϕ M (t) − Li L (t) = h(q M (t)) − Li L (t),
from which ∞ 1 invariant manifolds for the dynamics in the (v, i)-domain can be
found.