

148
4 Nonlinear Dynamics and Bifurcations in Autonomous RLC Circuits
E
−E
slope G a
slope G b
v
i
−4
−2
2
4
−2
2
v
i
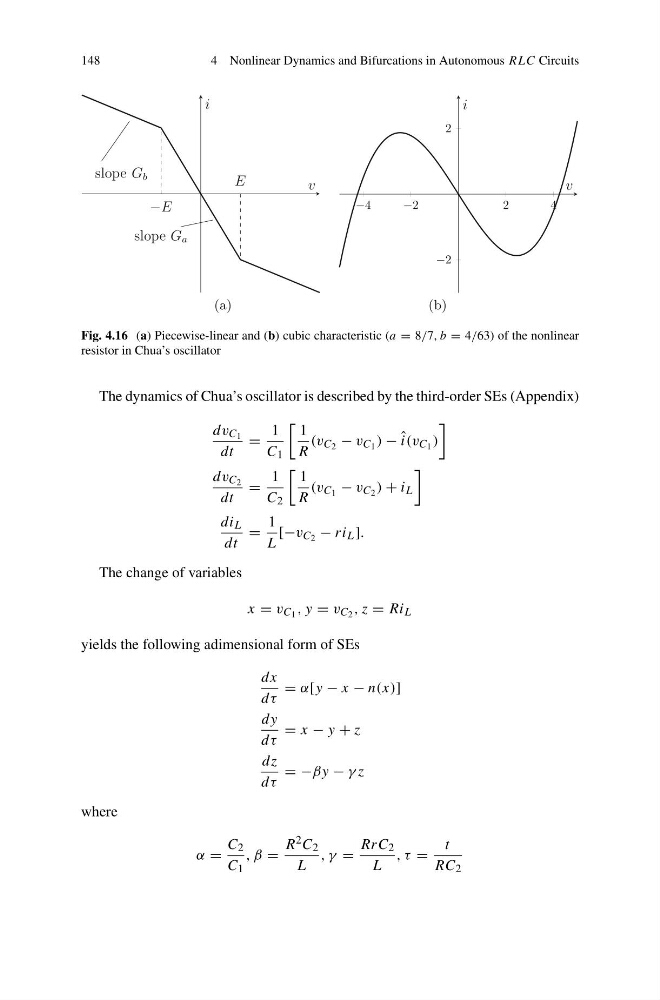
Fig. 4.16 (a) Piecewise-linear and (b) cubic characteristic (a = 8/7, b = 4/63) of the nonlinear
resistor in Chua’s oscillator
The dynamics of Chua’s oscillator is described by the third-order SEs (Appendix)
dv C 1
dt
=
1
C 1
1
R
(v C 2 − v C 1 ) − ˆ
i(v C 1 )
dv C 2
dt
=
1
C 2
1
R
(v C 1 − v C 2 ) + i L
di L
dt
=
1
L
[−v C 2 − ri L ].
The change of variables
x = v C 1 , y = v C 2 , z = Ri L
yields the following adimensional form of SEs
dx
dτ
= α[y − x − n(x)]
dy
dτ
= x − y + z
dz
dτ
= −βy − γ z
where
α =
C 2
C 1
, β =
R 2 C 2
L
, γ =
RrC 2
L
, τ =
t
RC 2