

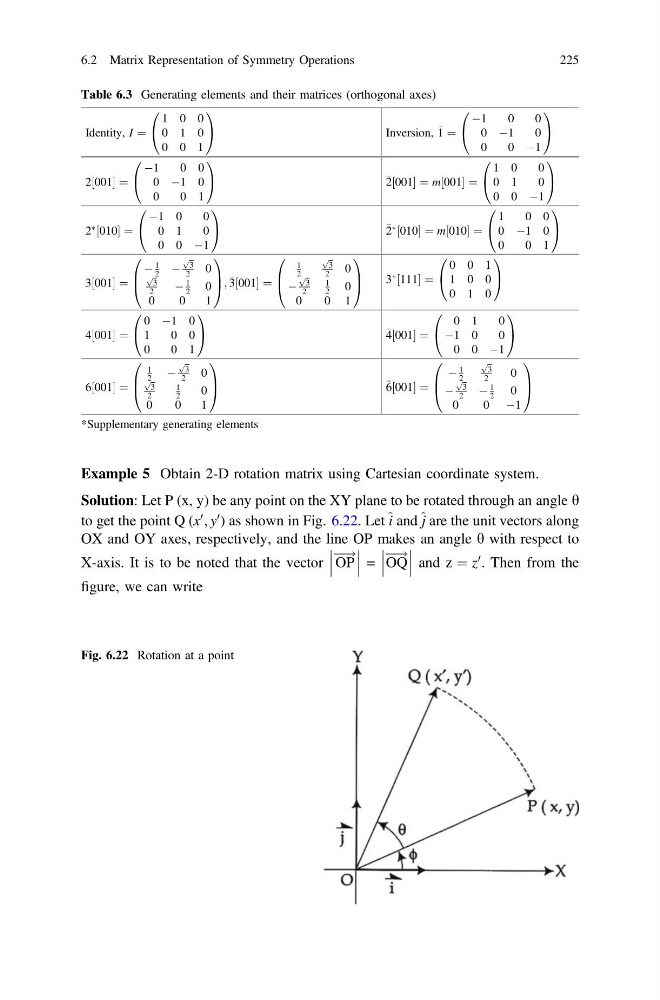
Example 5 Obtain 2-D rotation matrix using Cartesian coordinate system.
Solution: Let P (x, y) be any point on the XY plane to be rotated through an angle h
to get the point Q (x
0
; y
0 ) as shown in Fig. 6.22. Let ^ i and ^ j are the unit vectors along
OX and OY axes, respectively, and the line OP makes an angle h with respect to
X-axis. It is to be noted that the vector OP
!
= OQ
!
and z ¼ z
0 . Then from the
figure, we can write
Table 6.3 Generating elements and their matrices (orthogonal axes)
Identity, I ¼
1 0 0
0 1 0
0 0 1
0
@
1
A
Inversion, 1 ¼
À1
0
0
0 À1
0
0
0 À1
0
@
1
A
2 001
½ ¼
À1
0 0
0 À1 0
0
0 1
0
@
1
A
2 001
½ ¼m 001
½ ¼
1 0
0
0 1
0
0 0 À1
0
@
1
A
2
à 010
½ ¼
À1 0
0
0 1
0
0 0 À1
0
@
1
A
2
à 010
½
¼ m 010
½ ¼
1
0 0
0 À1 0
0
0 1
0
@
1
A
3 001
½ ¼
À
1
2 À
ffiffi
3
p
2
0
ffiffi
3
p
2
À
1
2
0
0
0
1
0
B
@
1
C
A; 3 001
½ ¼
1
2
ffiffi
3
p
2
0
À
ffiffi
3
p
2
1
2
0
0
0 1
0
B
@
1
C
A
3
à 111
½
¼
0 0 1
1 0 0
0 1 0
0
@
1
A
4 001
½ ¼
0 À1 0
1
0 0
0
0 1
0
@
1
A
4 001
½ ¼
0 1
0
À1 0
0
0 0 À1
0
@
1
A
6 001
½ ¼
1
2
À
ffiffi
3
p
2
0
ffiffi
3
p
2
1
2
0
0
0
1
0
B
@
1
C
A
6 001
½ ¼
À
1
2
ffiffi
3
p
2
0
À
ffiffi
3
p
2
À
1
2
0
0
0 À1
0
B
@
1
C
A
*Supplementary generating elements
Fig. 6.22 Rotation at a point
6.2 Matrix Representation of Symmetry Operations
225