

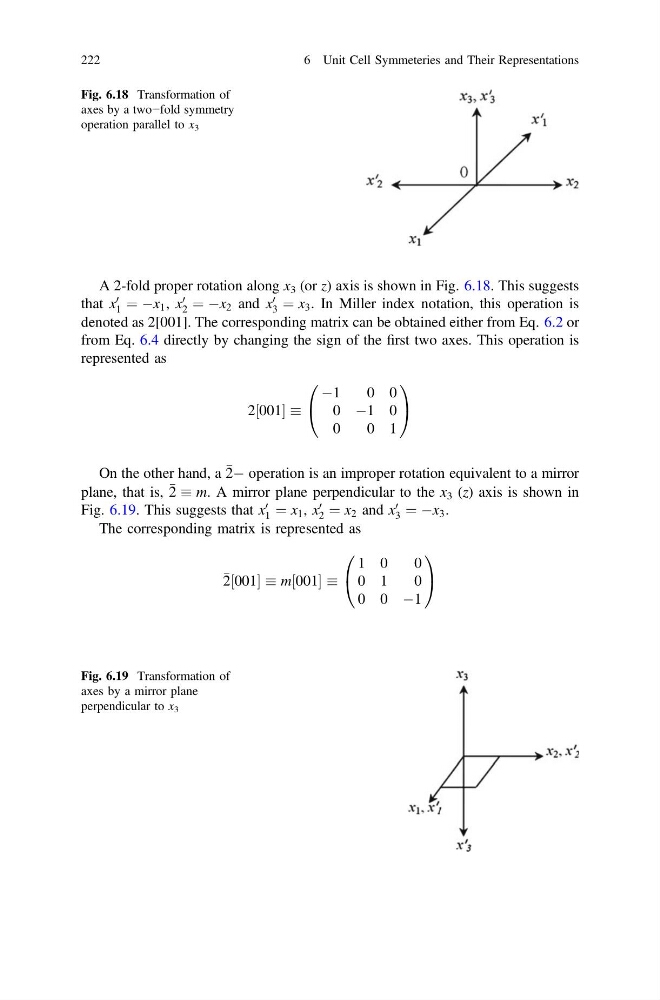
A 2-fold proper rotation along x 3 (or z) axis is shown in Fig. 6.18. This suggests
that x
0
1 ¼ Àx 1 , x
0
2 ¼ Àx 2 and x
0
3 ¼ x 3 . In Miller index notation, this operation is
denoted as 2[001]. The corresponding matrix can be obtained either from Eq. 6.2 or
from Eq. 6.4 directly by changing the sign of the first two axes. This operation is
represented as
2 001
½
À1
0 0
0 À1 0
0
0 1
0
@
1
A
On the other hand, a 2À operation is an improper rotation equivalent to a mirror
plane, that is, 2 m. A mirror plane perpendicular to the x 3 (z) axis is shown in
Fig. 6.19. This suggests that x
0
1 ¼ x 1 , x
0
2 ¼ x 2 and x
0
3 ¼ Àx 3 .
The corresponding matrix is represented as
2 001
½
m 001
½
1 0
0
0 1
0
0 0 À1
0
@
1
A
Fig. 6.18 Transformation of
axes by a two−fold symmetry
operation parallel to x 3
Fig. 6.19 Transformation of
axes by a mirror plane
perpendicular to x 3
222
6 Unit Cell Symmeteries and Their Representations