

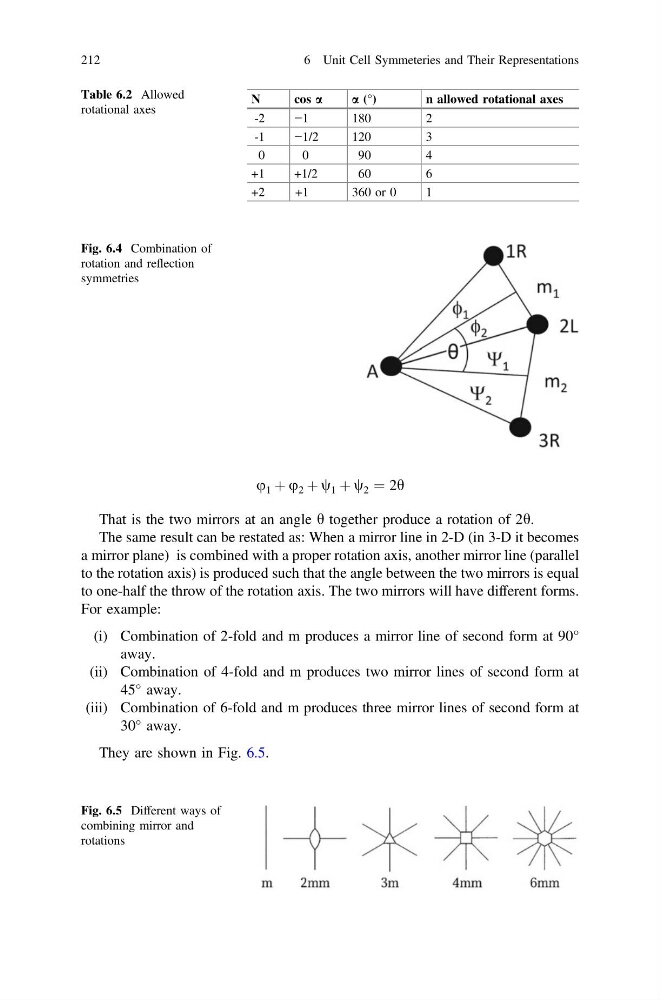
u 1 þ u 2 þ w 1 þ w 2 ¼ 2h
That is the two mirrors at an angle h together produce a rotation of 2h.
The same result can be restated as: When a mirror line in 2-D (in 3-D it becomes
a mirror plane) is combined with a proper rotation axis, another mirror line (parallel
to the rotation axis) is produced such that the angle between the two mirrors is equal
to one-half the throw of the rotation axis. The two mirrors will have different forms.
For example:
(i) Combination of 2-fold and m produces a mirror line of second form at 90°
away.
(ii) Combination of 4-fold and m produces two mirror lines of second form at
45° away.
(iii) Combination of 6-fold and m produces three mirror lines of second form at
30° away.
They are shown in Fig. 6.5.
Table 6.2 Allowed
rotational axes
N
cos a
a(°)
n allowed rotational axes
-2
−1
180
2
-1
−1/2
120
3
0
0
90
4
+1
+1/2
60
6
+2
+1
360 or 0
1
Fig. 6.4 Combination of
rotation and reflection
symmetries
Fig. 6.5 Different ways of
combining mirror and
rotations
212
6 Unit Cell Symmeteries and Their Representations