

In the matrix notation, this becomes
a
0
b
0
c
0
0
@
1
A ¼
0 À1 0
1 0 0
0 0 1
0
@
1
A
a
b
c
0
@
1
A
The corresponding fractional coordinates of the second point in 3-D are: (y, x, z).
However in 2-D, the matrix is
0 À1
1 0
and the corresponding fractional
coordinates of the second point are: (y, x). Further, considering the following
products of two matrices, we can obtain
0 À1
1 0
0 À1
1 0
¼
À1 0
0 À1
x;y
ð Þ
and
0 À1
1 0
À1 0
0 À1
¼
0 1
À1 0
y, x
ð
Þ
Hence, the fractional coordinates in 2-D are:
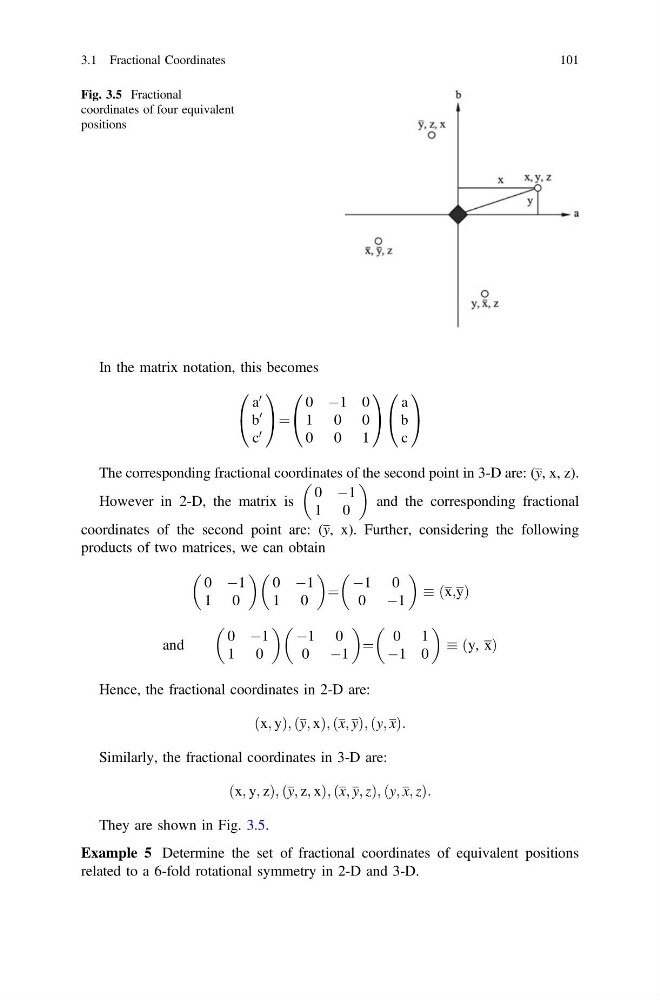
ðx; yÞ; ðy; xÞ; ðx; yÞ; ðy; xÞ:
Similarly, the fractional coordinates in 3-D are:
ðx; y; zÞ; ðy; z; xÞ; ðx; y; zÞ; ðy; x; zÞ:
They are shown in Fig. 3.5.
Example 5 Determine the set of fractional coordinates of equivalent positions
related to a 6-fold rotational symmetry in 2-D and 3-D.
Fig. 3.5 Fractional
coordinates of four equivalent
positions
3.1 Fractional Coordinates
101
a
0
b
0
c
0
0
@
1
A ¼
0 À1 0
1 0 0
0 0 1
0
@
1
A
a
b
c
0
@
1
A
The corresponding fractional coordinates of the second point in 3-D are: (y, x, z).
However in 2-D, the matrix is
0 À1
1 0
and the corresponding fractional
coordinates of the second point are: (y, x). Further, considering the following
products of two matrices, we can obtain
0 À1
1 0
0 À1
1 0
¼
À1 0
0 À1
x;y
ð Þ
and
0 À1
1 0
À1 0
0 À1
¼
0 1
À1 0
y, x
ð
Þ
Hence, the fractional coordinates in 2-D are:
ðx; yÞ; ðy; xÞ; ðx; yÞ; ðy; xÞ:
Similarly, the fractional coordinates in 3-D are:
ðx; y; zÞ; ðy; z; xÞ; ðx; y; zÞ; ðy; x; zÞ:
They are shown in Fig. 3.5.
Example 5 Determine the set of fractional coordinates of equivalent positions
related to a 6-fold rotational symmetry in 2-D and 3-D.
Fig. 3.5 Fractional
coordinates of four equivalent
positions
3.1 Fractional Coordinates
101