

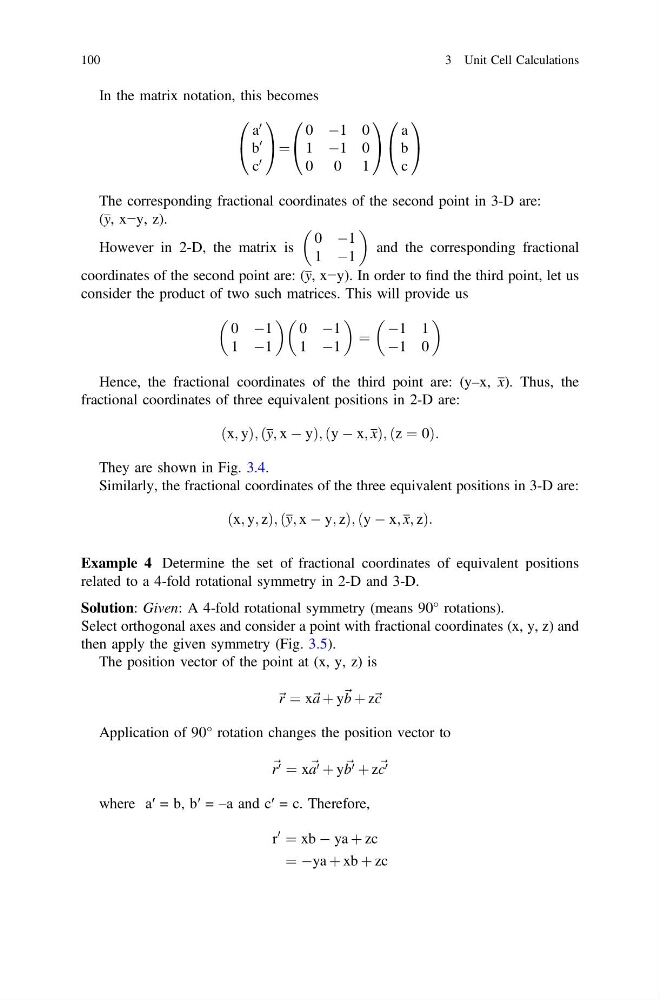
In the matrix notation, this becomes
a
0
b
0
c
0
0
@
1
A ¼
0 À1 0
1 À1 0
0 0 1
0
@
1
A
a
b
c
0
@
1
A
The corresponding fractional coordinates of the second point in 3-D are:
(y, x−y, z).
However in 2-D, the matrix is
0 À1
1 À1
and the corresponding fractional
coordinates of the second point are: (y, x−y). In order to find the third point, let us
consider the product of two such matrices. This will provide us
0 À1
1 À1
0 À1
1 À1
¼
À1 1
À1 0
Hence, the fractional coordinates of the third point are: (y–x, x). Thus, the
fractional coordinates of three equivalent positions in 2-D are:
ðx; yÞ; ðy; x À yÞ; ðy À x; xÞ; ðz ¼ 0Þ:
They are shown in Fig. 3.4.
Similarly, the fractional coordinates of the three equivalent positions in 3-D are:
ðx; y; zÞ; ðy; x À y; zÞ; ðy À x; x; zÞ:
Example 4 Determine the set of fractional coordinates of equivalent positions
related to a 4-fold rotational symmetry in 2-D and 3-D.
Solution: Given: A 4-fold rotational symmetry (means 90° rotations).
Select orthogonal axes and consider a point with fractional coordinates (x, y, z) and
then apply the given symmetry (Fig. 3.5).
The position vector of the point at (x, y, z) is
~ r ¼ x~ a þ y ~ b þ z~ c
Application of 90° rotation changes the position vector to
~ r 0 ¼ x ~
a 0 þ y ~
b 0 þ z ~ c 0
where a′ = b, b′ = –a and c′ = c. Therefore,
r
0
¼ xb À ya þ zc
¼ Àya þ xb þ zc
100
3 Unit Cell Calculations
a
0
b
0
c
0
0
@
1
A ¼
0 À1 0
1 À1 0
0 0 1
0
@
1
A
a
b
c
0
@
1
A
The corresponding fractional coordinates of the second point in 3-D are:
(y, x−y, z).
However in 2-D, the matrix is
0 À1
1 À1
and the corresponding fractional
coordinates of the second point are: (y, x−y). In order to find the third point, let us
consider the product of two such matrices. This will provide us
0 À1
1 À1
0 À1
1 À1
¼
À1 1
À1 0
Hence, the fractional coordinates of the third point are: (y–x, x). Thus, the
fractional coordinates of three equivalent positions in 2-D are:
ðx; yÞ; ðy; x À yÞ; ðy À x; xÞ; ðz ¼ 0Þ:
They are shown in Fig. 3.4.
Similarly, the fractional coordinates of the three equivalent positions in 3-D are:
ðx; y; zÞ; ðy; x À y; zÞ; ðy À x; x; zÞ:
Example 4 Determine the set of fractional coordinates of equivalent positions
related to a 4-fold rotational symmetry in 2-D and 3-D.
Solution: Given: A 4-fold rotational symmetry (means 90° rotations).
Select orthogonal axes and consider a point with fractional coordinates (x, y, z) and
then apply the given symmetry (Fig. 3.5).
The position vector of the point at (x, y, z) is
~ r ¼ x~ a þ y ~ b þ z~ c
Application of 90° rotation changes the position vector to
~ r 0 ¼ x ~
a 0 þ y ~
b 0 þ z ~ c 0
where a′ = b, b′ = –a and c′ = c. Therefore,
r
0
¼ xb À ya þ zc
¼ Àya þ xb þ zc
100
3 Unit Cell Calculations