

244
5 Blow That Horn: An Elementary Model of Brass Playing
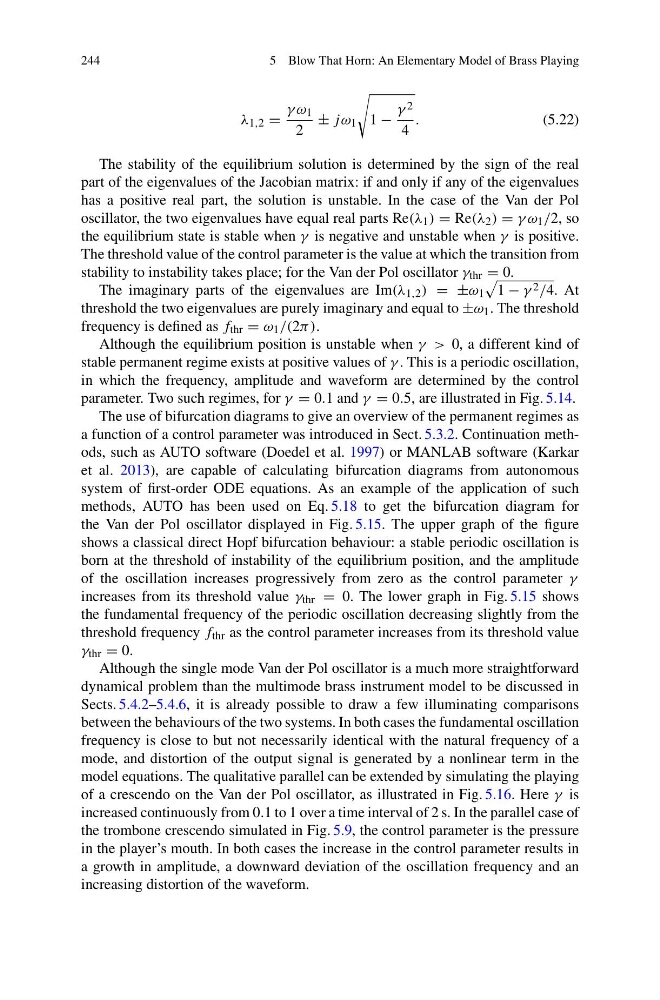
λ 1,2 =
γ ω 1
2
± jω 1
1 −
γ 2
4
.
(5.22)
The stability of the equilibrium solution is determined by the sign of the real
part of the eigenvalues of the Jacobian matrix: if and only if any of the eigenvalues
has a positive real part, the solution is unstable. In the case of the Van der Pol
oscillator, the two eigenvalues have equal real parts Re(λ 1 ) = Re(λ 2 ) = γ ω 1 /2, so
the equilibrium state is stable when γ is negative and unstable when γ is positive.
The threshold value of the control parameter is the value at which the transition from
stability to instability takes place; for the Van der Pol oscillator γ thr = 0.
The imaginary parts of the eigenvalues are Im(λ 1,2 ) = ±ω 1
1 − γ 2 /4. At
threshold the two eigenvalues are purely imaginary and equal to ±ω 1 . The threshold
frequency is defined as f thr = ω 1 /(2π).
Although the equilibrium position is unstable when γ > 0, a different kind of
stable permanent regime exists at positive values of γ . This is a periodic oscillation,
in which the frequency, amplitude and waveform are determined by the control
parameter. Two such regimes, for γ = 0.1 and γ = 0.5, are illustrated in Fig. 5.14.
The use of bifurcation diagrams to give an overview of the permanent regimes as
a function of a control parameter was introduced in Sect. 5.3.2. Continuation methods, such as AUTO software (Doedel et al. 1997) or MANLAB software (Karkar
et al. 2013), are capable of calculating bifurcation diagrams from autonomous
system of first-order ODE equations. As an example of the application of such
methods, AUTO has been used on Eq. 5.18 to get the bifurcation diagram for
the Van der Pol oscillator displayed in Fig. 5.15. The upper graph of the figure
shows a classical direct Hopf bifurcation behaviour: a stable periodic oscillation is
born at the threshold of instability of the equilibrium position, and the amplitude
of the oscillation increases progressively from zero as the control parameter γ
increases from its threshold value γ thr = 0. The lower graph in Fig. 5.15 shows
the fundamental frequency of the periodic oscillation decreasing slightly from the
threshold frequency f thr as the control parameter increases from its threshold value
γ thr = 0.
Although the single mode Van der Pol oscillator is a much more straightforward
dynamical problem than the multimode brass instrument model to be discussed in
Sects. 5.4.2–5.4.6, it is already possible to draw a few illuminating comparisons
between the behaviours of the two systems. In both cases the fundamental oscillation
frequency is close to but not necessarily identical with the natural frequency of a
mode, and distortion of the output signal is generated by a nonlinear term in the
model equations. The qualitative parallel can be extended by simulating the playing
of a crescendo on the Van der Pol oscillator, as illustrated in Fig. 5.16. Here γ is
increased continuously from 0.1 to 1 over a time interval of 2 s. In the parallel case of
the trombone crescendo simulated in Fig. 5.9, the control parameter is the pressure
in the player’s mouth. In both cases the increase in the control parameter results in
a growth in amplitude, a downward deviation of the oscillation frequency and an
increasing distortion of the waveform.