

256
7 Guidance, Navigation and Control Technology …
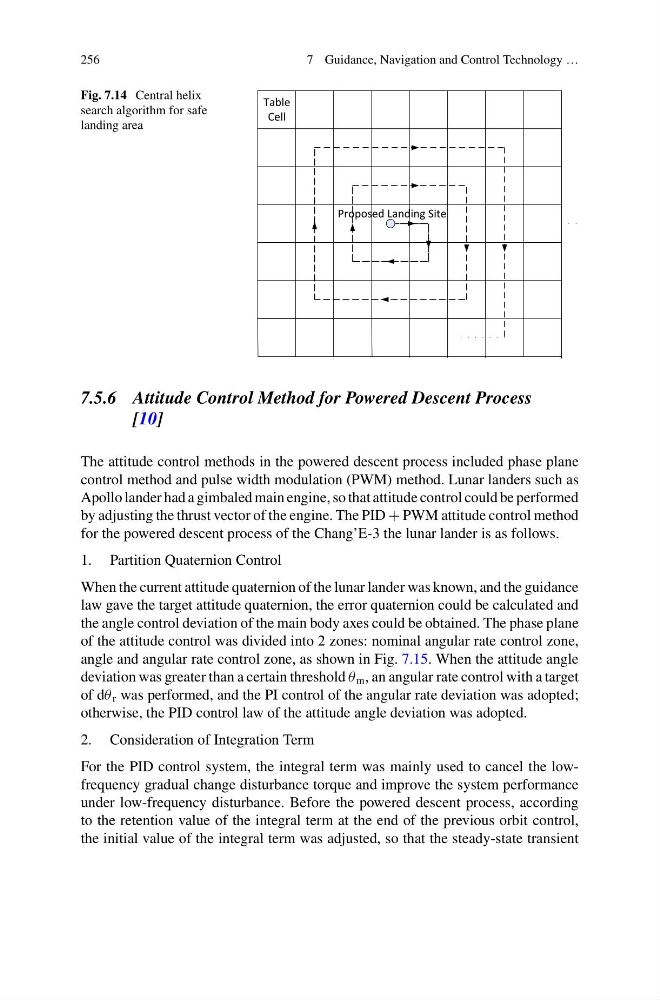
Fig. 7.14 Central helix
search algorithm for safe
landing area
Table
Cell
Proposed Landing Site
7.5.6 Attitude Control Method for Powered Descent Process
[10]
The attitude control methods in the powered descent process included phase plane
control method and pulse width modulation (PWM) method. Lunar landers such as
Apollo lander had a gimbaled main engine, so that attitude control could be performed
by adjusting the thrust vector of the engine. The PID + PWM attitude control method
for the powered descent process of the Chang’E-3 the lunar lander is as follows.
1. Partition Quaternion Control
When the current attitude quaternion of the lunar lander was known, and the guidance
law gave the target attitude quaternion, the error quaternion could be calculated and
the angle control deviation of the main body axes could be obtained. The phase plane
of the attitude control was divided into 2 zones: nominal angular rate control zone,
angle and angular rate control zone, as shown in Fig. 7.15. When the attitude angle
deviation was greater than a certain threshold θ m , an angular rate control with a target
of dθ r was performed, and the PI control of the angular rate deviation was adopted;
otherwise, the PID control law of the attitude angle deviation was adopted.
2. Consideration of Integration Term
For the PID control system, the integral term was mainly used to cancel the lowfrequency gradual change disturbance torque and improve the system performance
under low-frequency disturbance. Before the powered descent process, according
to the retention value of the integral term at the end of the previous orbit control,
the initial value of the integral term was adjusted, so that the steady-state transient