

31 Research on Immersion-Type Acoustic Emission …
369
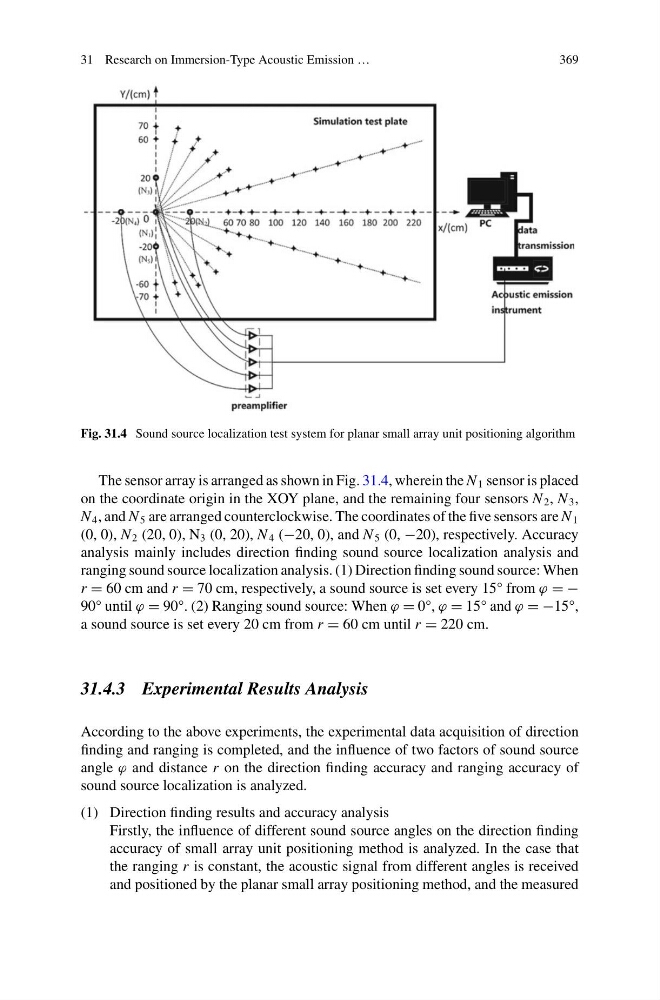
Fig. 31.4 Sound source localization test system for planar small array unit positioning algorithm
The sensor array is arranged as shown in Fig. 31.4, wherein the N 1 sensor is placed
on the coordinate origin in the XOY plane, and the remaining four sensors N 2 , N 3 ,
N 4 , and N 5 are arranged counterclockwise. The coordinates of the five sensors are N 1
(0, 0), N 2 (20, 0), N 3 (0, 20), N 4 (−20, 0), and N 5 (0, −20), respectively. Accuracy
analysis mainly includes direction finding sound source localization analysis and
ranging sound source localization analysis. (1) Direction finding sound source: When
r = 60 cm and r = 70 cm, respectively, a sound source is set every 15° from ϕ = −
90° until ϕ = 90°. (2) Ranging sound source: When ϕ = 0°, ϕ = 15° and ϕ = −15°,
a sound source is set every 20 cm from r = 60 cm until r = 220 cm.
31.4.3 Experimental Results Analysis
According to the above experiments, the experimental data acquisition of direction
finding and ranging is completed, and the influence of two factors of sound source
angle ϕ and distance r on the direction finding accuracy and ranging accuracy of
sound source localization is analyzed.
(1) Direction finding results and accuracy analysis
Firstly, the influence of different sound source angles on the direction finding
accuracy of small array unit positioning method is analyzed. In the case that
the ranging r is constant, the acoustic signal from different angles is received
and positioned by the planar small array positioning method, and the measured