

366
J. Gao et al.
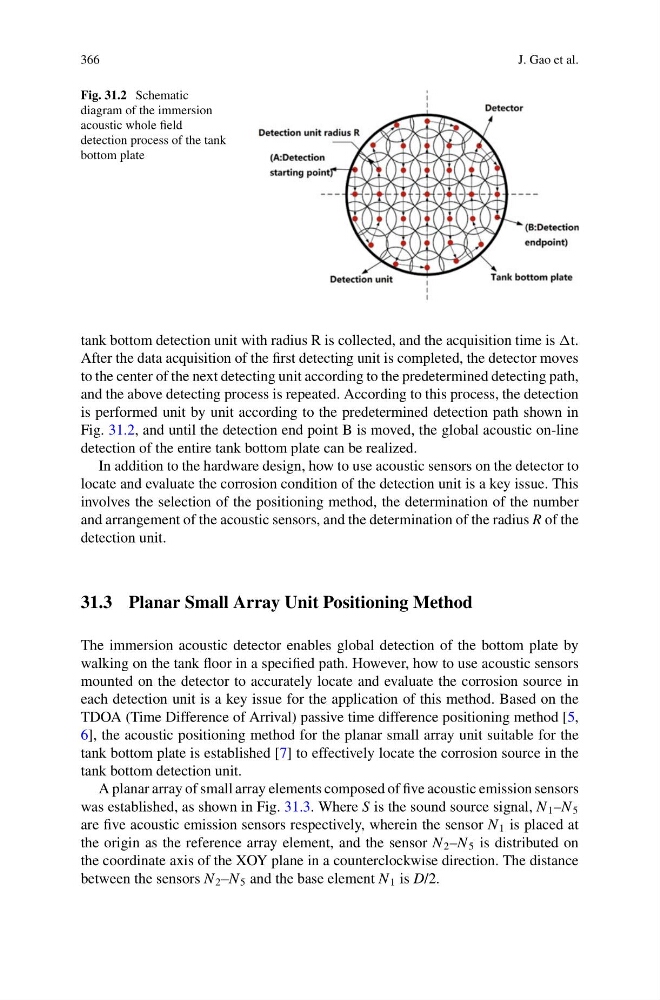
Fig. 31.2 Schematic
diagram of the immersion
acoustic whole field
detection process of the tank
bottom plate
tank bottom detection unit with radius R is collected, and the acquisition time is t.
After the data acquisition of the first detecting unit is completed, the detector moves
to the center of the next detecting unit according to the predetermined detecting path,
and the above detecting process is repeated. According to this process, the detection
is performed unit by unit according to the predetermined detection path shown in
Fig. 31.2, and until the detection end point B is moved, the global acoustic on-line
detection of the entire tank bottom plate can be realized.
In addition to the hardware design, how to use acoustic sensors on the detector to
locate and evaluate the corrosion condition of the detection unit is a key issue. This
involves the selection of the positioning method, the determination of the number
and arrangement of the acoustic sensors, and the determination of the radius R of the
detection unit.
31.3 Planar Small Array Unit Positioning Method
The immersion acoustic detector enables global detection of the bottom plate by
walking on the tank floor in a specified path. However, how to use acoustic sensors
mounted on the detector to accurately locate and evaluate the corrosion source in
each detection unit is a key issue for the application of this method. Based on the
TDOA (Time Difference of Arrival) passive time difference positioning method [5,
6], the acoustic positioning method for the planar small array unit suitable for the
tank bottom plate is established [7] to effectively locate the corrosion source in the
tank bottom detection unit.
A planar array of small array elements composed of five acoustic emission sensors
was established, as shown in Fig. 31.3. Where S is the sound source signal, N 1 –N 5
are five acoustic emission sensors respectively, wherein the sensor N 1 is placed at
the origin as the reference array element, and the sensor N 2 –N 5 is distributed on
the coordinate axis of the XOY plane in a counterclockwise direction. The distance
between the sensors N 2 –N 5 and the base element N 1 is D/2.