

434
D Invariant Measures
¯
O
T
= ¯
O
−1 so ¯
O
T
· ¯
O = ¯
O· ¯
O
T
= ¯
1,
(D.9)
where ¯
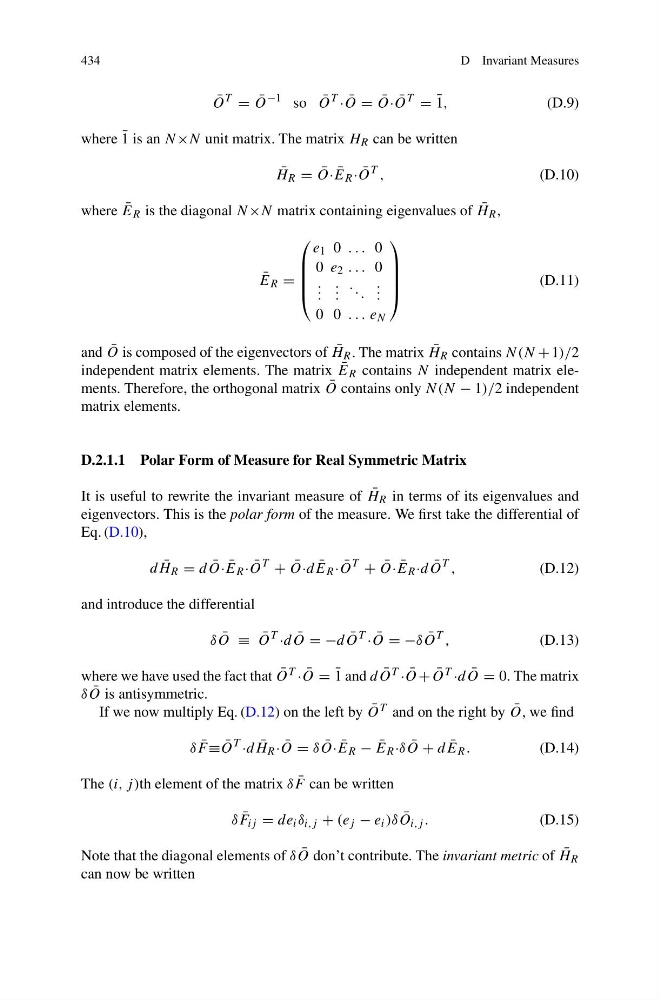
1 is an N×N unit matrix. The matrix H R can be written
¯
H R = ¯
O· ¯
E R · ¯
O
T ,
(D.10)
where ¯
E R is the diagonal N×N matrix containing eigenvalues of ¯
H R ,
¯
E R =
⎛
⎜
⎜
⎜
⎝
e 1 0 . . . 0
0 e 2 . . . 0
. . .
. . .
. . .
. . .
0 0 . . . e N
⎞
⎟
⎟
⎟
⎠
(D.11)
and ¯
O is composed of the eigenvectors of ¯
H R . The matrix ¯
H R contains N(N + 1)/2
independent matrix elements. The matrix ¯
E R contains N independent matrix elements. Therefore, the orthogonal matrix ¯
O contains only N(N − 1)/2 independent
matrix elements.
D.2.1.1 Polar Form of Measure for Real Symmetric Matrix
It is useful to rewrite the invariant measure of ¯
H R in terms of its eigenvalues and
eigenvectors. This is the polar form of the measure. We first take the differential of
Eq. (D.10),
d ¯
H R = d ¯
O· ¯
E R · ¯
O
T
+ ¯
O·d ¯
E R · ¯
O
T
+ ¯
O· ¯
E R ·d ¯
O
T ,
(D.12)
and introduce the differential
δ ¯
O ≡ ¯
O
T
·d ¯
O = −d ¯
O
T
· ¯
O = −δ ¯
O
T ,
(D.13)
where we have used the fact that ¯
O T · ¯
O = ¯
1 and d ¯
O T · ¯
O + ¯
O T ·d ¯
O = 0. The matrix
δ ¯
O is antisymmetric.
If we now multiply Eq. (D.12) on the left by ¯
O T and on the right by ¯
O, we find
δ ¯
F ≡ ¯
O
T
·d ¯
H R · ¯
O = δ ¯
O· ¯
E R − ¯
E R ·δ ¯
O + d ¯
E R .
(D.14)
The (i, j )th element of the matrix δ ¯
F can be written
δ ¯
F ij = de i δ i,j + (e j − e i )δ ¯
O i,j .
(D.15)
Note that the diagonal elements of δ ¯
O don’t contribute. The invariant metric of ¯
H R
can now be written