

D.2 Hermitian Matrices
433
matrices with these same symmetry properties. Dyson showed that these three
symmetry classes exhaust the possibilities available to us in nonrelativistic systems
Dyson (1962).
D.2 Hermitian Matrices
In this section, we derive the invariant measures for three different types of
Hermitian matrices: real symmetric, complex Hermitian, and quaternion real. These
correspond to the Hamiltonians for the three dynamical symmetry classes described
above.
D.2.1 Real Symmetric Matrix
Hamiltonians that govern the dynamics of systems that are invariant under time
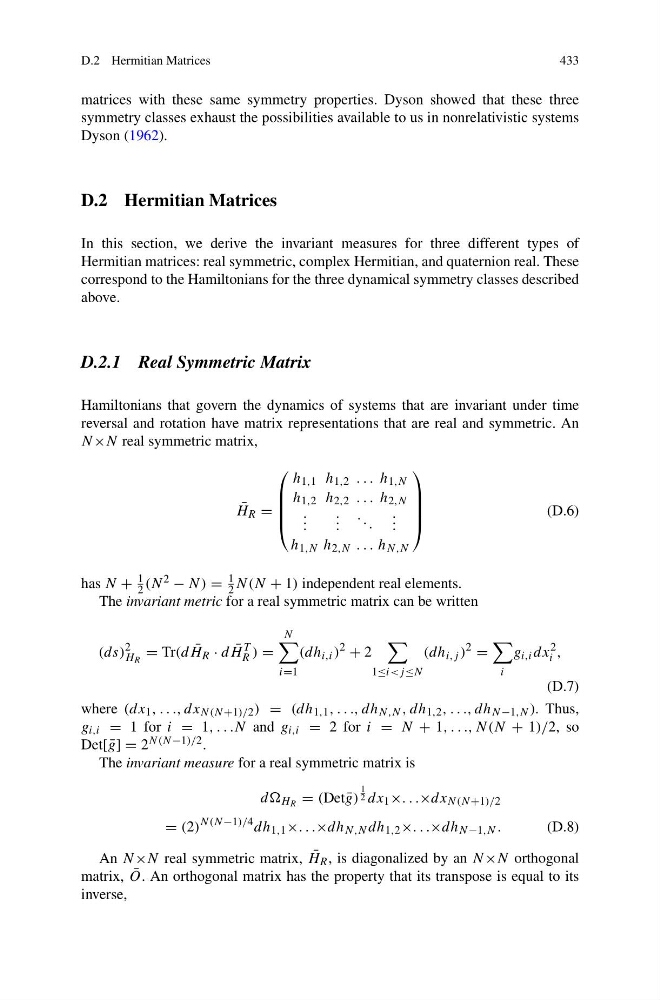
reversal and rotation have matrix representations that are real and symmetric. An
N ×N real symmetric matrix,
¯
H R =
⎛
⎜
⎜
⎜
⎝
h 1,1 h 1,2 . . . h 1,N
h 1,2 h 2,2 . . . h 2,N
. . .
. . .
. . .
. . .
h 1,N h 2,N . . . h N,N
⎞
⎟
⎟
⎟
⎠
(D.6)
has N +
1
2 (N 2 − N) =
1
2 N(N + 1) independent real elements.
The invariant metric for a real symmetric matrix can be written
(ds)
2
H R
= Tr(d ¯
H R · d ¯
H
T
R ) =
N
i=1
(dh i,i )
2
+ 2
1≤i
2
=
i
g i,i dx
2
i ,
(D.7)
where (dx 1 , . . ., dx N(N+1)/2 ) = (dh 1,1 , . . ., dh N,N , dh 1,2 , . . ., dh N −1,N ). Thus,
g i,i = 1 for i = 1, . . .N and g i,i = 2 for i = N + 1, . . ., N(N + 1)/2, so
Det[ ¯
g] = 2 N(N−1)/2 .
The invariant measure for a real symmetric matrix is
dd H R = (Det ¯
g)
1
2 dx 1 ×. . .×dx N(N+1)/2
= (2)
N(N−1)/4 dh 1,1 ×. . .×dh N,N dh 1,2 ×. . .×dh N −1,N .
(D.8)
An N×N real symmetric matrix, ¯
H R , is diagonalized by an N ×N orthogonal
matrix, ¯
O. An orthogonal matrix has the property that its transpose is equal to its
inverse,