

3.8 Renormalization Map
93
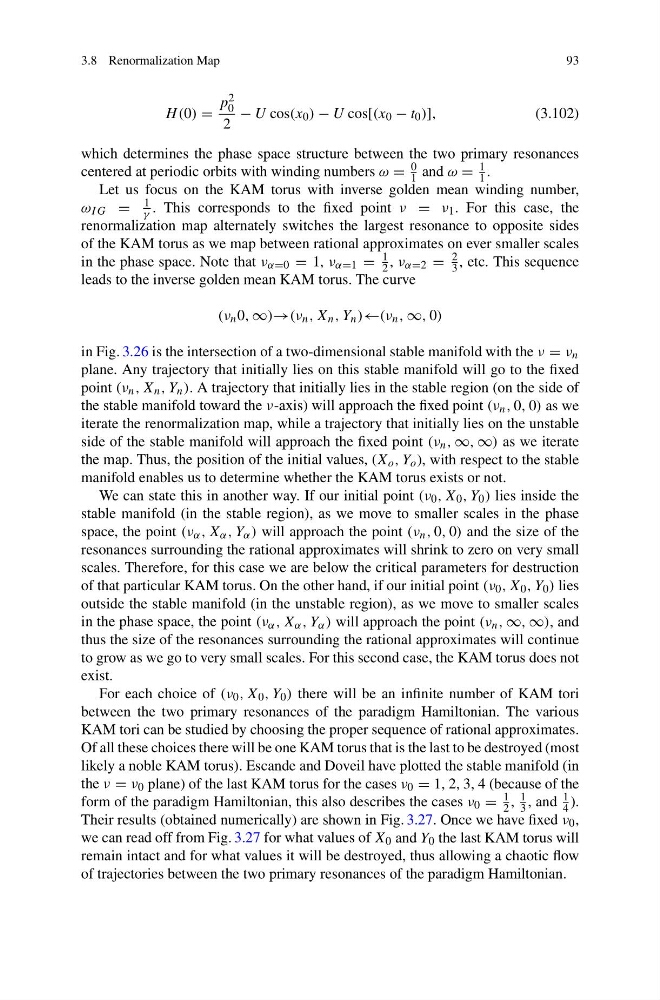
H (0) =
p 2
0
2
− U cos(x 0 ) − U cos[(x 0 − t 0 )],
(3.102)
which determines the phase space structure between the two primary resonances
centered at periodic orbits with winding numbers ω =
0
1 and ω =
1
1 .
Let us focus on the KAM torus with inverse golden mean winding number,
ω I G =
1
γ . This corresponds to the fixed point ν = ν 1 . For this case, the
renormalization map alternately switches the largest resonance to opposite sides
of the KAM torus as we map between rational approximates on ever smaller scales
in the phase space. Note that ν α=0 = 1, ν α=1 =
1
2 , ν α=2 =
2
3 , etc. This sequence
leads to the inverse golden mean KAM torus. The curve
(ν n 0, ∞)→(ν n , X n , Y n )←(ν n , ∞, 0)
in Fig. 3.26 is the intersection of a two-dimensional stable manifold with the ν = ν n
plane. Any trajectory that initially lies on this stable manifold will go to the fixed
point (ν n , X n , Y n ). A trajectory that initially lies in the stable region (on the side of
the stable manifold toward the ν-axis) will approach the fixed point (ν n , 0, 0) as we
iterate the renormalization map, while a trajectory that initially lies on the unstable
side of the stable manifold will approach the fixed point (ν n , ∞, ∞) as we iterate
the map. Thus, the position of the initial values, (X o , Y o ), with respect to the stable
manifold enables us to determine whether the KAM torus exists or not.
We can state this in another way. If our initial point (ν 0 , X 0 , Y 0 ) lies inside the
stable manifold (in the stable region), as we move to smaller scales in the phase
space, the point (ν α , X α , Y α ) will approach the point (ν n , 0, 0) and the size of the
resonances surrounding the rational approximates will shrink to zero on very small
scales. Therefore, for this case we are below the critical parameters for destruction
of that particular KAM torus. On the other hand, if our initial point (ν 0 , X 0 , Y 0 ) lies
outside the stable manifold (in the unstable region), as we move to smaller scales
in the phase space, the point (ν α , X α , Y α ) will approach the point (ν n , ∞, ∞), and
thus the size of the resonances surrounding the rational approximates will continue
to grow as we go to very small scales. For this second case, the KAM torus does not
exist.
For each choice of (ν 0 , X 0 , Y 0 ) there will be an infinite number of KAM tori
between the two primary resonances of the paradigm Hamiltonian. The various
KAM tori can be studied by choosing the proper sequence of rational approximates.
Of all these choices there will be one KAM torus that is the last to be destroyed (most
likely a noble KAM torus). Escande and Doveil have plotted the stable manifold (in
the ν = ν 0 plane) of the last KAM torus for the cases ν 0 = 1, 2, 3, 4 (because of the
form of the paradigm Hamiltonian, this also describes the cases ν 0 =
1
2 ,
1
3 , and
1
4 ).
Their results (obtained numerically) are shown in Fig. 3.27. Once we have fixed ν 0 ,
we can read off from Fig. 3.27 for what values of X 0 and Y 0 the last KAM torus will
remain intact and for what values it will be destroyed, thus allowing a chaotic flow
of trajectories between the two primary resonances of the paradigm Hamiltonian.