

6
1 Basic Terms and Definitions
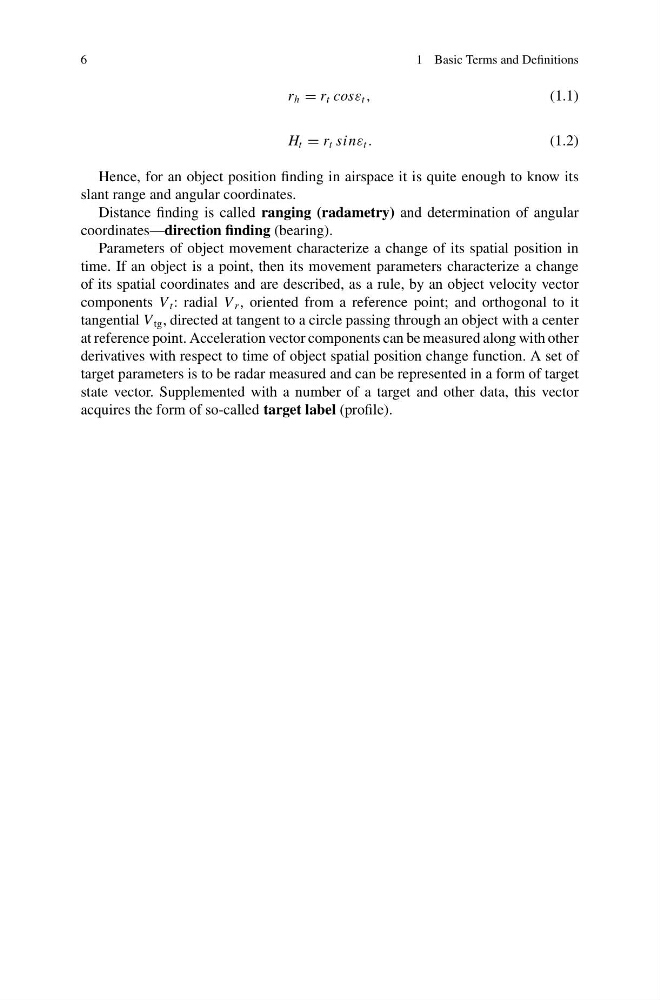
r h = r t cosε t ,
(1.1)
H t = r t sinε t .
(1.2)
Hence, for an object position finding in airspace it is quite enough to know its
slant range and angular coordinates.
Distance finding is called ranging (radametry) and determination of angular
coordinates—direction finding (bearing).
Parameters of object movement characterize a change of its spatial position in
time. If an object is a point, then its movement parameters characterize a change
of its spatial coordinates and are described, as a rule, by an object velocity vector
components V t : radial V r , oriented from a reference point; and orthogonal to it
tangential V tg , directed at tangent to a circle passing through an object with a center
at reference point. Acceleration vector components can be measured along with other
derivatives with respect to time of object spatial position change function. A set of
target parameters is to be radar measured and can be represented in a form of target
state vector. Supplemented with a number of a target and other data, this vector
acquires the form of so-called target label (profile).