

74
3 Elasticity
(t)
a
E=1
=
σ(t)
σ a
:=
⎧
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎩
t − t 0
t 1 − t 0
1
t 3 − t
t 3 − t 2
⎫
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎭
for
⎧
⎪ ⎪ ⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎪ ⎪ ⎩
t 0 ≤ t ≤ t 1
t 1 ≤ t ≤ t 2
t 2 ≤ t ≤ t 3
⎫
⎪ ⎪ ⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎪ ⎪ ⎭
(3.27)
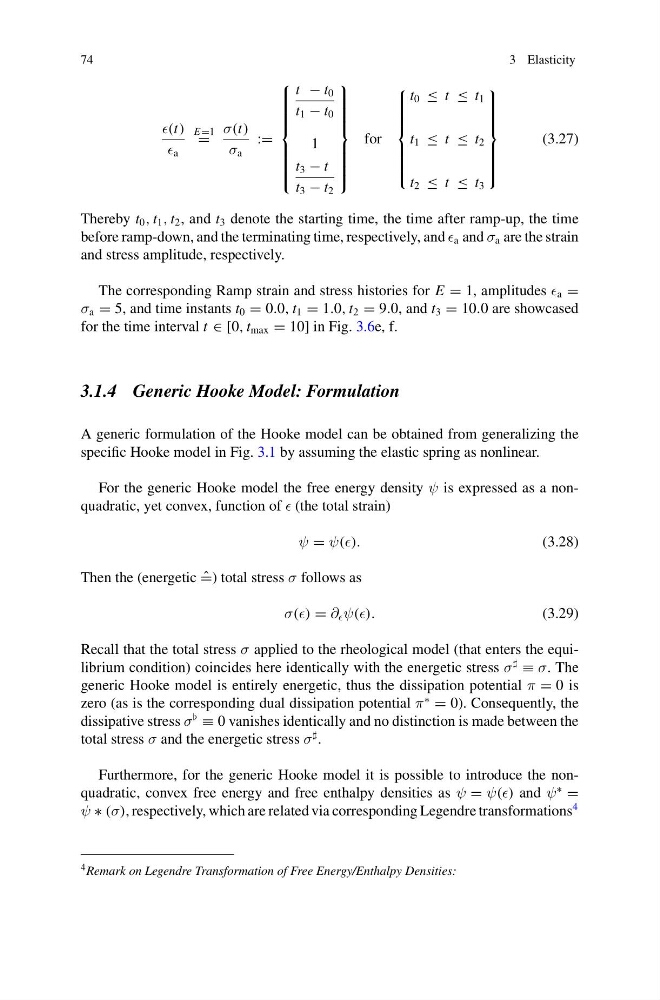
Thereby t 0 , t 1 , t 2 , and t 3 denote the starting time, the time after ramp-up, the time
before ramp-down, and the terminating time, respectively, and a and σ a are the strain
and stress amplitude, respectively.
The corresponding Ramp strain and stress histories for E = 1, amplitudes a =
σ a = 5, and time instants t 0 = 0.0, t 1 = 1.0, t 2 = 9.0, and t 3 = 10.0 are showcased
for the time interval t ∈ [0, t max = 10] in Fig. 3.6e, f.
3.1.4 Generic Hooke Model: Formulation
A generic formulation of the Hooke model can be obtained from generalizing the
specific Hooke model in Fig. 3.1 by assuming the elastic spring as nonlinear.
For the generic Hooke model the free energy density ψ is expressed as a nonquadratic, yet convex, function of (the total strain)
ψ = ψ().
(3.28)
Then the (energetic ˆ
=) total stress σ follows as
σ() = ∂ ψ().
(3.29)
Recall that the total stress σ applied to the rheological model (that enters the equilibrium condition) coincides here identically with the energetic stress σ
≡ σ. The
generic Hooke model is entirely energetic, thus the dissipation potential π = 0 is
zero (as is the corresponding dual dissipation potential π
∗
= 0). Consequently, the
dissipative stress σ
≡ 0 vanishes identically and no distinction is made between the
total stress σ and the energetic stress σ
.
Furthermore, for the generic Hooke model it is possible to introduce the nonquadratic, convex free energy and free enthalpy densities as ψ = ψ() and ψ
∗
=
ψ ∗ (σ), respectively, which are related via corresponding Legendre transformations
4
4 Remark on Legendre Transformation of Free Energy/Enthalpy Densities: