

144
4 Visco-Elasticity
¯
d 1 = ¯
π 1 (˙ v 1 ) + ¯
π
∗
1 (σ v 1 ) ≥ 0 and ¯
d k = ¯
π k (˙ v k ) + ¯
π
∗
k (σ v k ) ≥ 0.
(4.140)
The generic Generalized-Kelvin model is summarized in Table 4.9.
4.4 Maxwell Model
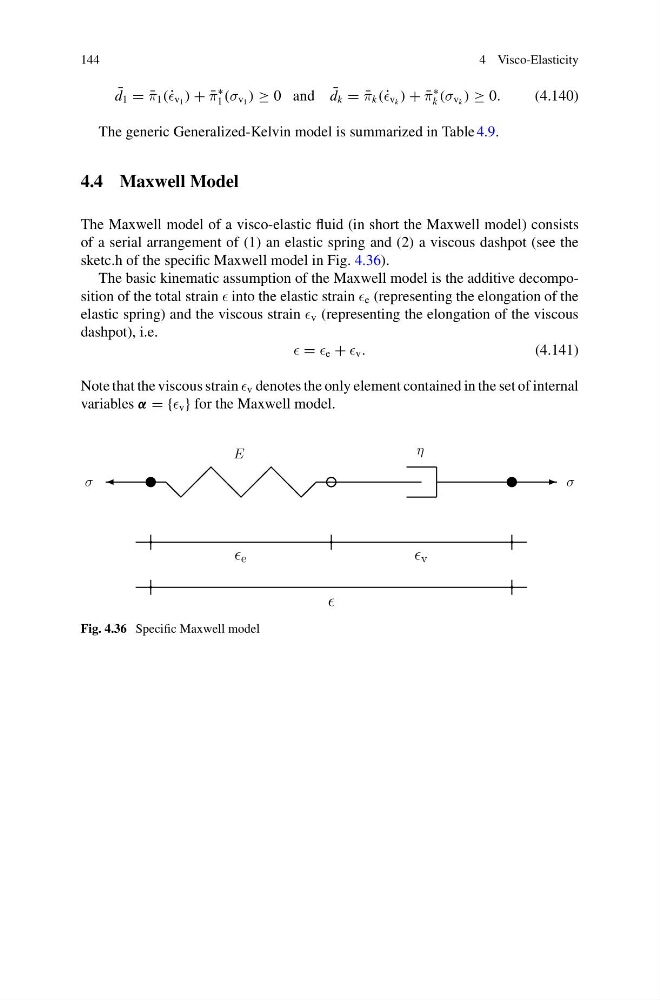
The Maxwell model of a visco-elastic fluid (in short the Maxwell model) consists
of a serial arrangement of (1) an elastic spring and (2) a viscous dashpot (see the
sketc.h of the specific Maxwell model in Fig. 4.36).
The basic kinematic assumption of the Maxwell model is the additive decomposition of the total strain into the elastic strain e (representing the elongation of the
elastic spring) and the viscous strain v (representing the elongation of the viscous
dashpot), i.e.
= e + v .
(4.141)
Note that the viscous strain v denotes the only element contained in the set of internal
variables α = { v } for the Maxwell model.
σ
σ
e
v
E
η
Fig. 4.36 Specific Maxwell model