

130
4 Visco-Elasticity
σ
σ
˜ e
˜ v
E ∞ := E 0 E k /[E 0 + E k ]
E m := E
2
0 /[E 0 + E k ] η m := η k E
2
0 /[E 0 + E k ]
2
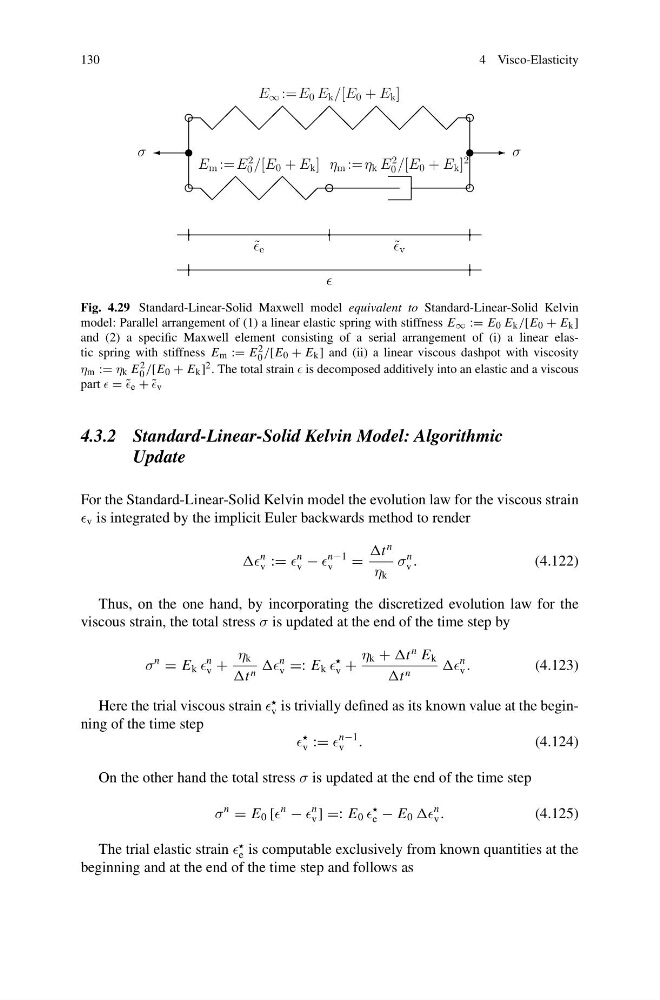
Fig. 4.29 Standard-Linear-Solid Maxwell model equivalent to Standard-Linear-Solid Kelvin
model: Parallel arrangement of (1) a linear elastic spring with stiffness E ∞ := E 0 E k /[E 0 + E k ]
and (2) a specific Maxwell element consisting of a serial arrangement of (i) a linear elastic spring with stiffness E m := E 2
0 /[E 0 + E k ] and (ii) a linear viscous dashpot with viscosity
η m := η k E 2
0 /[E 0 + E k ] 2 . The total strain is decomposed additively into an elastic and a viscous
part = ˜
e + ˜
v
4.3.2 Standard-Linear-Solid Kelvin Model: Algorithmic
Update
For the Standard-Linear-Solid Kelvin model the evolution law for the viscous strain
v is integrated by the implicit Euler backwards method to render
n
v :=
n
v −
n−1
v
=
n
η k
σ
n
v .
(4.122)
Thus, on the one hand, by incorporating the discretized evolution law for the
viscous strain, the total stress σ is updated at the end of the time step by
σ
n
= E k
n
v +
η k
t n
n
v =: E k
v +
η k +
n E k
t n
n
v .
(4.123)
Here the trial viscous strain
v is trivially defined as its known value at the beginning of the time step
v :=
n−1
v .
(4.124)
On the other hand the total stress σ is updated at the end of the time step
σ
n
= E 0 [
n
−
n
v ] =: E 0
e − E 0
n
v .
(4.125)
The trial elastic strain
e is computable exclusively from known quantities at the
beginning and at the end of the time step and follows as