

4.3 Generalized-Kelvin Model
131
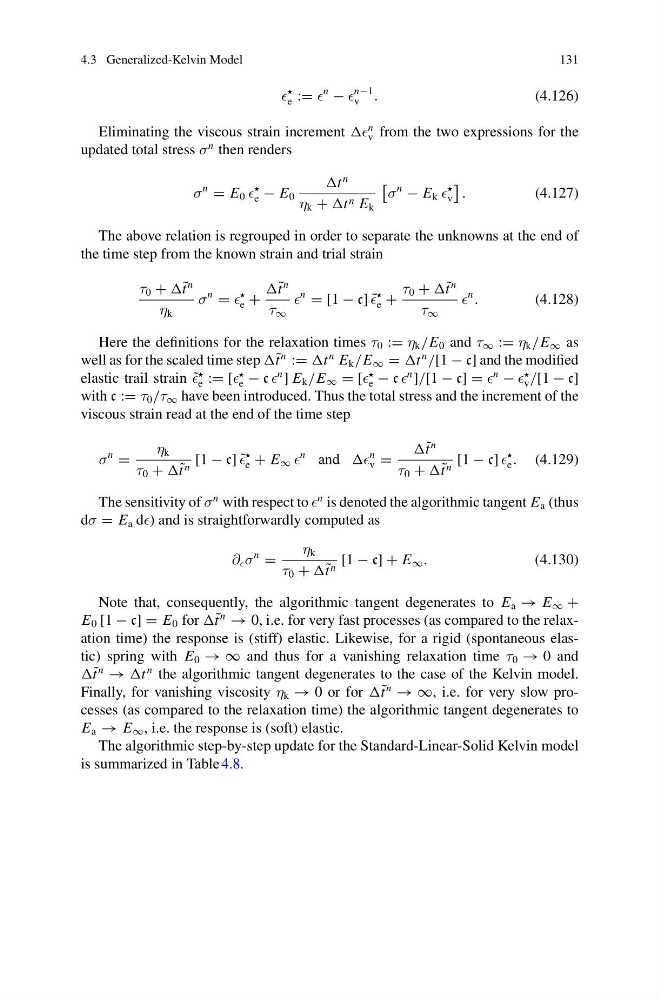
e :=
n
−
n−1
v .
(4.126)
Eliminating the viscous strain increment
n
v from the two expressions for the
updated total stress σ
n then renders
σ
n
= E 0
e − E 0
t
n
η k + t n E k
σ
n
− E k
v
.
(4.127)
The above relation is regrouped in order to separate the unknowns at the end of
the time step from the known strain and trial strain
τ 0 + ˜ t
n
η k
σ
n
=
e +
˜ t
n
τ ∞
n
= [1 − c] ˜
e +
τ 0 + ˜ t
n
τ ∞
n
.
(4.128)
Here the definitions for the relaxation times τ 0 := η k /E 0 and τ ∞ := η k /E ∞ as
well as for the scaled time step ˜ t
n
:= t
n E k /E ∞ = t
n
/[1 − c] and the modified
elastic trail strain ˜
e := [
e − c
n
] E k /E ∞ = [
e − c
n
]/[1 − c] =
n
−
v /[1 − c]
with c := τ 0 /τ ∞ have been introduced. Thus the total stress and the increment of the
viscous strain read at the end of the time step
σ
n
=
η k
τ 0 + ˜ t n [1 − c] ˜
e + E ∞
n and
n
v =
˜ t
n
τ 0 + ˜ t n [1 − c]
e . (4.129)
The sensitivity of σ
n with respect to
n is denoted the algorithmic tangent E a (thus
dσ = E a d) and is straightforwardly computed as
∂ σ
n
=
η k
τ 0 + ˜ t n [1 − c] + E ∞ .
(4.130)
Note that, consequently, the algorithmic tangent degenerates to E a → E ∞ +
E 0 [1 − c] = E 0 for ˜ t
n
→ 0, i.e. for very fast processes (as compared to the relaxation time) the response is (stiff) elastic. Likewise, for a rigid (spontaneous elastic) spring with E 0 → ∞ and thus for a vanishing relaxation time τ 0 → 0 and
˜ t
n
→ t
n the algorithmic tangent degenerates to the case of the Kelvin model.
Finally, for vanishing viscosity η k → 0 or for ˜ t
n
→ ∞, i.e. for very slow processes (as compared to the relaxation time) the algorithmic tangent degenerates to
E a → E ∞ , i.e. the response is (soft) elastic.
The algorithmic step-by-step update for the Standard-Linear-Solid Kelvin model
is summarized in Table 4.8.