

F.1 Stochastic Energetics
177
F.1.1 Sekimoto View
Ken Sekimoto [3] faced the question of how Langevin dynamics is related to the
first and second law of equilibrium and also non-equilibrium thermodynamics, in
doing so he considered U = U(x, a) in Eq. F.10 where a represents the effect of an
external agent (or agents), with an external force F a = −∂U (x, a)/∂a, then dU ,
dU =
∂U (x, a)
∂x
dx +
∂U (x, a)
∂a
da
(F.13)
Then the Eq. F.10 transform in, where we have added a load force, F L ,
d
dt
p 2
2m
−
p
m
∂U
∂a
= −
p 2
m 2 +
m
k B T −
p
m
∂U
∂x
−
p
m
∂U
∂a
−
p
m
F L
+
p
m
F (t)
(F.14)
where we have added −
p
m
∂U
∂a
on the left side of the former equation in order to
equilibrate it. Written in another way, where we have used Eq. F.10, then
dE k
dt
+
dW ext
dt
= +
dQ
dt
−
dU
dt
−
dW L
dt
+
dW drive
dt
(F.15)
where
dQ
dt
= −
p 2
m 2 +
m
k B T
(F.16)
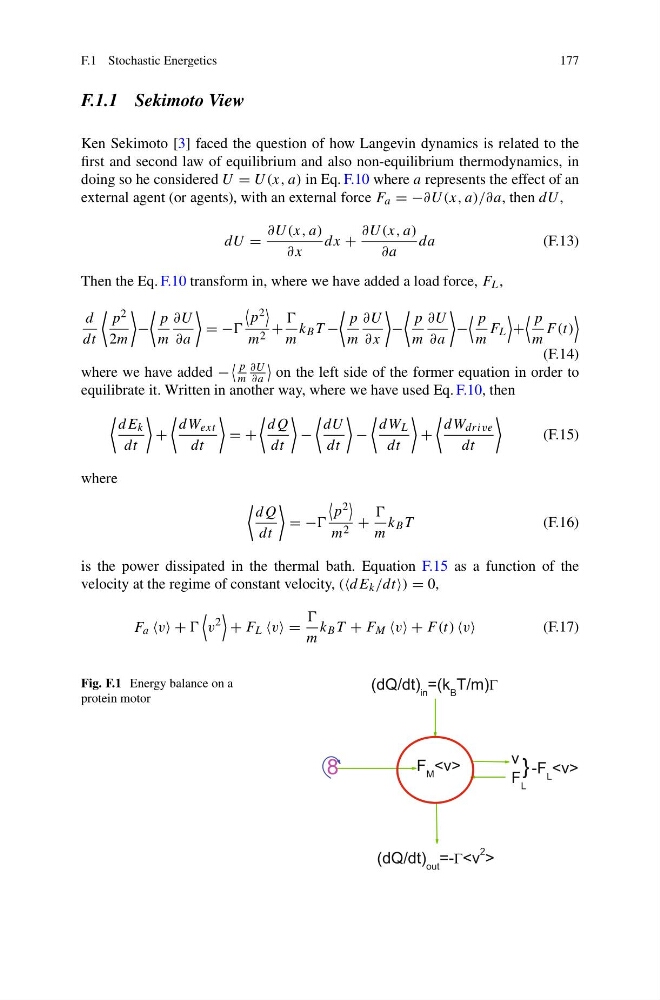
is the power dissipated in the thermal bath. Equation F.15 as a function of the
velocity at the regime of constant velocity, (dE k /dt) = 0,
F a v +
v
2
+ F L v =
m
k B T + F M v + F (t) v
(F.17)
Fig. F.1 Energy balance on a
protein motor