

31 Lane Detection Using Image Processing for Driving Assistance
331
31.4 Experimental Results
The pixel resolution used in this experiment was 620 × 480 in the early stage because
of the fact that the processing time can be reduced and the entire process gets faster.
As the result, the images produced were of low quality because the number of pixels
has been reduced but it was still acceptable. In the image enhancement, the numbers
of the pixels in the picture are being sharpened by removing the noise and by adjusting
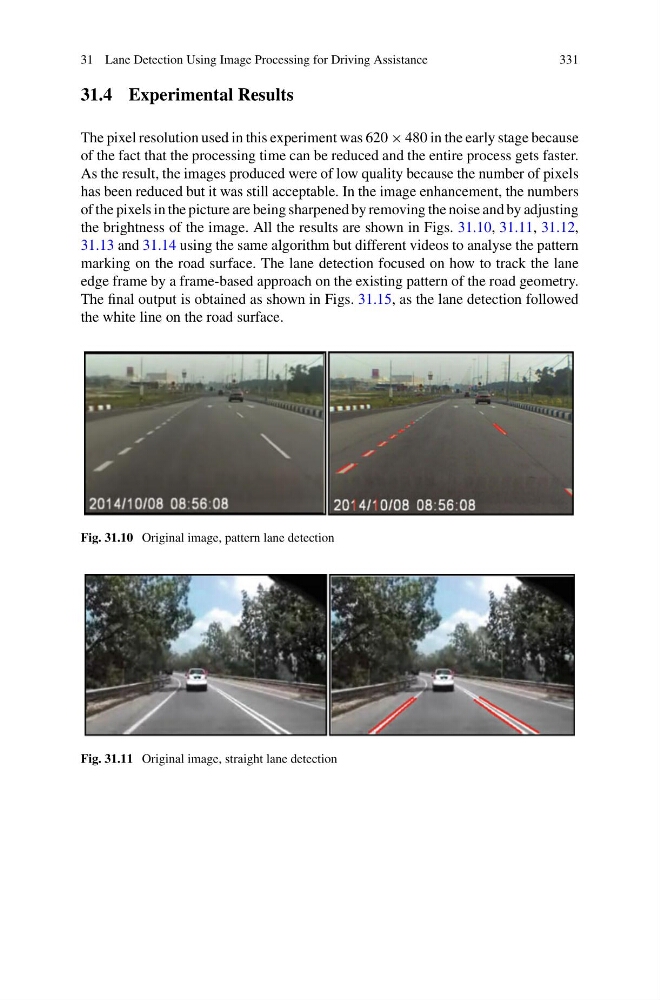
the brightness of the image. All the results are shown in Figs. 31.10, 31.11, 31.12,
31.13 and 31.14 using the same algorithm but different videos to analyse the pattern
marking on the road surface. The lane detection focused on how to track the lane
edge frame by a frame-based approach on the existing pattern of the road geometry.
The final output is obtained as shown in Figs. 31.15, as the lane detection followed
the white line on the road surface.
Fig. 31.10 Original image, pattern lane detection
Fig. 31.11 Original image, straight lane detection