

31 Lane Detection Using Image Processing for Driving Assistance
329
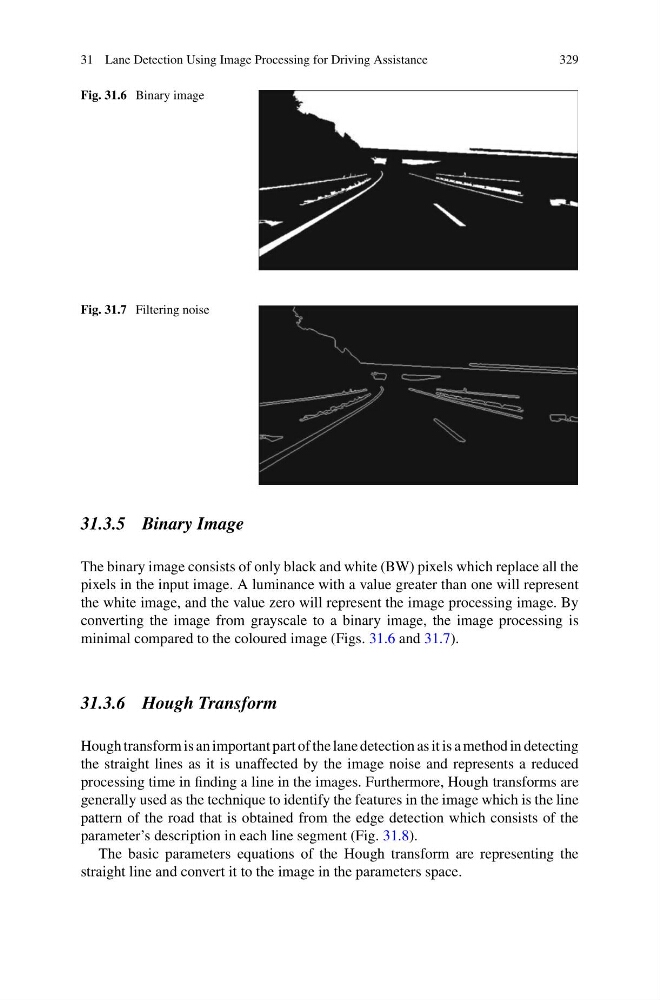
Fig. 31.6 Binary image
Fig. 31.7 Filtering noise
31.3.5 Binary Image
The binary image consists of only black and white (BW) pixels which replace all the
pixels in the input image. A luminance with a value greater than one will represent
the white image, and the value zero will represent the image processing image. By
converting the image from grayscale to a binary image, the image processing is
minimal compared to the coloured image (Figs. 31.6 and 31.7).
31.3.6 Hough Transform
Hough transform is an important part of the lane detection as it is a method in detecting
the straight lines as it is unaffected by the image noise and represents a reduced
processing time in finding a line in the images. Furthermore, Hough transforms are
generally used as the technique to identify the features in the image which is the line
pattern of the road that is obtained from the edge detection which consists of the
parameter’s description in each line segment (Fig. 31.8).
The basic parameters equations of the Hough transform are representing the
straight line and convert it to the image in the parameters space.