

90
5 Higher Order Moment Robust Filtering …
0
20
40
60
80
100
−0.05
0
0.05
0.1
0.15
0.2
0.25
0.3
t/s
e
e p1
e p2
e
p3
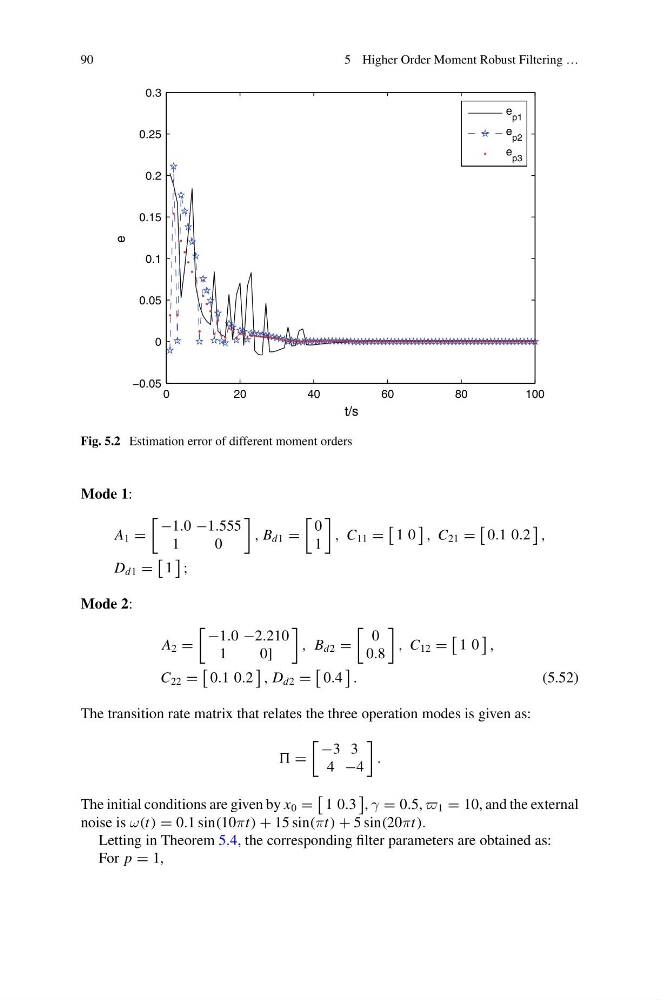
Fig. 5.2 Estimation error of different moment orders
Mode 1:
A 1 =
−1.0 −1.555
1
0
, B d1 =
0
1
, C 11 =
1 0
, C 21 =
0.1 0.2
,
D d1 =
1
;
Mode 2:
A 2 =
−1.0 −2.210
1
0]
, B d2 =
0
0.8
, C 12 =
1 0
,
C 22 =
0.1 0.2
, D d2 =
0.4
.
(5.52)
The transition rate matrix that relates the three operation modes is given as:
=
−3 3
4 −4
.
The initial conditions are given by x 0 =
1 0.3
, γ = 0.5, 1 = 10, and the external
noise is ω(t) = 0.1 sin(10πt) + 15 sin(πt) + 5 sin(20πt).
Letting in Theorem 5.4, the corresponding filter parameters are obtained as:
For p = 1,