

78
5 Higher Order Moment Robust Filtering …
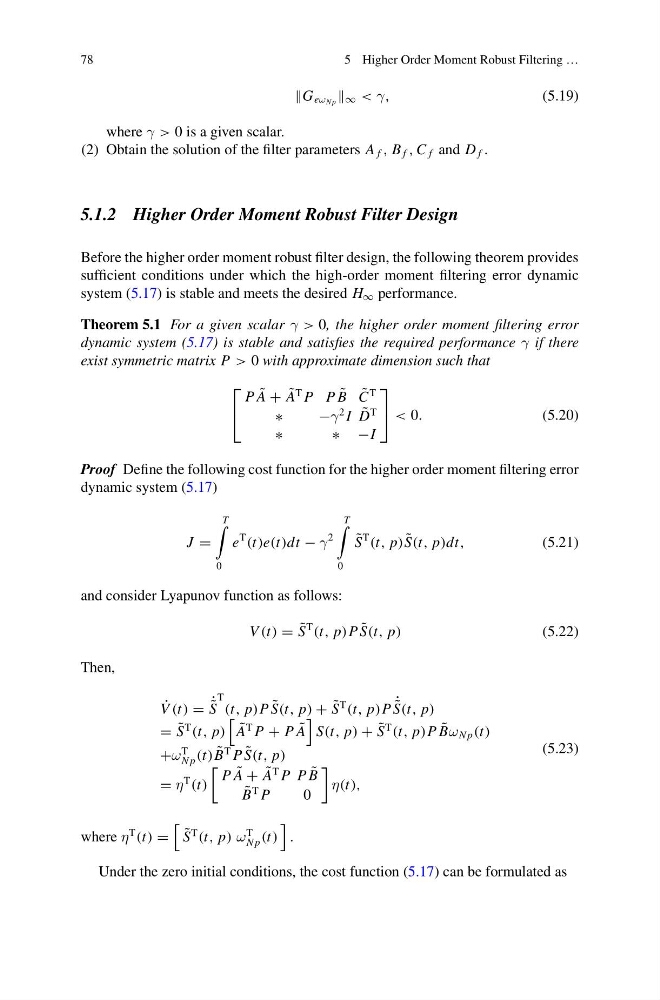
G eω N p ∞ < γ,
(5.19)
where γ > 0 is a given scalar.
(2) Obtain the solution of the filter parameters A f , B f , C f and D f .
5.1.2 Higher Order Moment Robust Filter Design
Before the higher order moment robust filter design, the following theorem provides
sufficient conditions under which the high-order moment filtering error dynamic
system (5.17) is stable and meets the desired H ∞ performance.
Theorem 5.1 For a given scalar γ > 0, the higher order moment filtering error
dynamic system (5.17) is stable and satisfies the required performance γ if there
exist symmetric matrix P > 0 with approximate dimension such that
⎡
⎣
P ˜
A + ˜
A
T P P ˜
B ˜
C
T
∗
−γ
2 I ˜
D
T
∗
∗ −I
⎤
⎦ < 0.
(5.20)
Proof Define the following cost function for the higher order moment filtering error
dynamic system (5.17)
J =
T
0
e
T
(t)e(t)dt − γ
2
T
0
˜
S
T
(t, p) ˜
S(t, p)dt,
(5.21)
and consider Lyapunov function as follows:
V (t) = ˜
S
T
(t, p)P ˜
S(t, p)
(5.22)
Then,
˙
V (t) = ˙ ˜
S
T (t, p)P ˜
S(t, p) + ˜
S
T
(t, p)P ˙ ˜
S(t, p)
= ˜
S
T
(t, p)
˜
A
T P + P ˜
A
S(t, p) + ˜
S
T
(t, p)P ˜
Bω N p (t)
+ω
T
N p (t) ˜
B
T P ˜
S(t, p)
= η
T
(t)
P ˜
A + ˜
A
T P P ˜
B
˜
B
T P
0
η(t),
(5.23)
where η
T
(t) =
˜
S
T
(t, p) ω
T
N p (t)
.
Under the zero initial conditions, the cost function (5.17) can be formulated as