

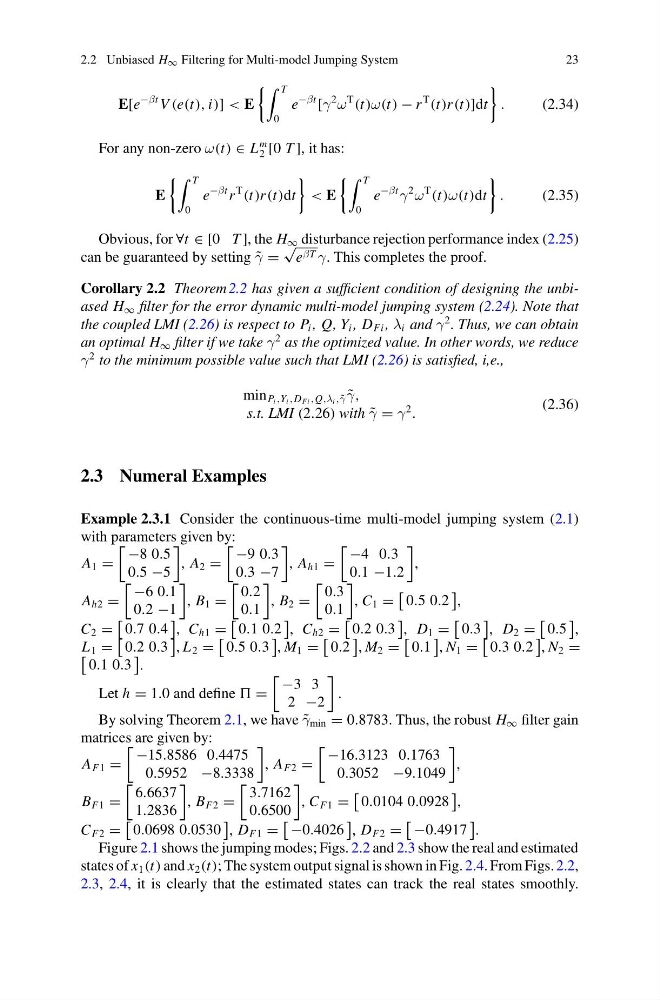
2.2 Unbiased H ∞ Filtering for Multi-model Jumping System
23
E[e
−βt V (e(t), i)] < E
T
0
e
−βt
[γ
2
ω
T
(t)ω(t) − r
T
(t)r (t)]dt
.
(2.34)
For any non-zero ω(t) ∈ L
m
2 [0 T ], it has:
E
T
0
e
−βt r
T
(t)r (t)dt
< E
T
0
e
−βt
γ
2
ω
T
(t)ω(t)dt
.
(2.35)
Obvious, for ∀t ∈ [0 T ], the H ∞ disturbance rejection performance index (2.25)
can be guaranteed by setting ˜
γ =
√
e βT γ. This completes the proof.
Corollary 2.2 Theorem 2.2 has given a sufficient condition of designing the unbiased H ∞ filter for the error dynamic multi-model jumping system (2.24). Note that
the coupled LMI (2.26) is respect to P i , Q, Y i , D Fi , λ i and γ
2 . Thus, we can obtain
an optimal H ∞ filter if we take γ
2 as the optimized value. In other words, we reduce
γ
2 to the minimum possible value such that LMI (2.26) is satisfied, i,e.,
min P i ,Y i ,D Fi ,Q,λ i , ˜
γ ˜
γ,
s.t. LMI (2.26) with ˜
γ = γ
2
.
(2.36)
2.3 Numeral Examples
Example 2.3.1 Consider the continuous-time multi-model jumping system (2.1)
with parameters given by:
A 1 =
−8 0.5
0.5 −5
, A 2 =
−9 0.3
0.3 −7
, A h1 =
−4 0.3
0.1 −1.2
,
A h2 =
−6 0.1
0.2 −1
, B 1 =
0.2
0.1
, B 2 =
0.3
0.1
, C 1 =
0.5 0.2
,
C 2 =
0.7 0.4
, C h1 =
0.1 0.2
, C h2 =
0.2 0.3
, D 1 =
0.3
, D 2 =
0.5
,
L 1 =
0.2 0.3
, L 2 =
0.5 0.3
, M 1 =
0.2
, M 2 =
0.1
, N 1 =
0.3 0.2
, N 2 =
0.1 0.3
.
Let h = 1.0 and define =
−3 3
2 −2
.
By solving Theorem 2.1, we have ˜
γ min = 0.8783. Thus, the robust H ∞ filter gain
matrices are given by:
A F1 =
−15.8586 0.4475
0.5952 −8.3338
, A F2 =
−16.3123 0.1763
0.3052 −9.1049
,
B F1 =
6.6637
1.2836
, B F2 =
3.7162
0.6500
, C F1 =
0.0104 0.0928
,
C F2 =
0.0698 0.0530
, D F1 =
−0.4026
, D F2 =
−0.4917
.
Figure 2.1 shows the jumping modes; Figs. 2.2 and 2.3 show the real and estimated
states of x 1 (t) and x 2 (t); The system output signal is shown in Fig. 2.4. From Figs. 2.2,
2.3, 2.4, it is clearly that the estimated states can track the real states smoothly.